Free tools Windows power users keep installed
One-click scans. No signup required.
A GNSS rover is the mobile survey receiver carried or mounted at the points a crew needs to measure or stake out. In real-time kinematic (RTK) surveying, it combines satellite observations with correction data from a base receiver or reference network to calculate its position relative to that reference. The result can be highly precise, but it is only dependable for a construction project when the reference coordinates, coordinate system, antenna setup, field conditions, and independent checks are also right.
What a GNSS rover does on a construction site
The rover is the moving part of a GNSS survey setup. A surveyor uses it to collect coordinates at site features—such as corners, grade points, or control marks—or to navigate to coordinates that need to be staked out. A rover may be mounted on a survey pole, vehicle, vessel, or backpack, depending on the receiver and job. NOAA’s NGS real-time positioning guidelines define the rover as a mobile receiver; Trimble’s rover guidance describes common mounting configurations.
As an Amazon Associate I earn from qualifying purchases.
GNSS is the general term for satellite navigation systems; GPS is one of them. A receiver can calculate a standalone position from satellite signals, but survey-grade RTK work uses a correction source to determine a more precise position relative to a reference. That distinction matters on construction work: a precise point is useful only if it is tied to the project’s intended control and coordinate system.
The Tool Desk
Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →How the rover calculates a position
Satellite observations provide the starting point
GNSS satellites transmit timed radio signals. The receiver uses observations from multiple satellites to estimate ranges and calculate a position. The FAA explains that GPS uses signals from at least four satellites to determine location and time and accounts for delays as signals travel through the atmosphere. The FAA’s description of basic GPS service—approximately 7.0 meters of accuracy 95% of the time anywhere on or near Earth’s surface—is about standalone basic GPS, not survey-grade RTK. See the FAA explanation of how GPS works.
#1 Best Overall

- 【60°Tilt Surveying】E1 Lite GNSS Surveying System with IMU, can initializes in 5 seconds and supports tilt measurements up to 60°, and compatible with regular 5/8" thread poles.
- 【20 Hours Endurance 】E1 Lite rtk handheld gps provides 6700mah over 20 hours of continuous operation on a single charge, with fast Type-C charging. It employs a base station and rover with the (GPS) to attain Centimeter-Level Precision Measurement, High precision with low power consumption, small size easy to carry and operate.
- 【10-15 Kilometers】E1 Lite GNSS RTK Survey equipment with IMU has a long transmission distance, radio range between the rover and the base can reach 10-15 kilometers (6.21-9.32miles). Also E1 Lite can compatible with base stations of other brands in both Radio and CORS mode. Support RTCM v3/CMR correction data transmission.
- 【Robust Signal Tracking】E1 Lite RTK support Full-Constellation Tracking: GPS/GLONASS/Galileo/BDS/QZSS/IRNSS/SBAS etc, an easily obtain fixed RTK solution in seconds even in challenging environments like multipath, trees, and city canyons.
- 【Various Interfaces】E1 Lite gps rtk Innovative integration of multiple connection methods: NFC (Touch connection) /Bluetooth/USB Type-C/WiFi/TNC Connector/RS232 Serial Port. Easily access static data download, Configuration, device Status check, and Firmware Upgrade.Improve your work efficiency by 30%!!
RTK uses a reference to refine the relative position
In RTK, the rover processes carrier-phase observations alongside correction data from a stationary base receiver or a reference network. Comparing observations at the rover and reference lets the system calculate a baseline vector between their antennas. The rover’s position is then determined relative to the reference coordinates. The antenna position must also be related correctly to the ground point being surveyed, using the antenna and pole height.
NOAA describes classical single-base RTK as producing three-dimensional positions relative to a fixed base, with expected relative accuracy “on the order of a centimeter” in each coordinate component using minimal epochs. That is a description of expected relative performance under the method’s operating assumptions—not a promise that every measured point will be within a centimeter of its true project coordinate. See NOAA Manual NOS NGS 9.
Rank #2
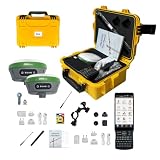
- 【High Capability & Compatibility】 The SMA26 Plus is an full-constellation RTK GNSS receiver with wide protocol compatibility, making it compatible with multiple RTK brands. Supporting PPP, PPK, and RTK technologies, it delivers versatile, high-precision performance for a wide range of surveying applications
- 【Tilt Compensation】 The SMA26 Plus RTK offers tilt measurement accuracy of up to 2.5 cm (at tilt angles ≤30°), after simple initialization, it is suitable for precise measurements in locations with limited signal or restricted space. The maximum tilt measurement angle is 60°
- 【Wide Protocol Compatibility】 SMA26 Plus GNSS RTK capable of receiving and broadcasting signals compatible with CSS(Lora),Transparent, TT450S,Trimtalk, TRMMARK3, SOUTH, SATEL standard radio protocols. ensuring compatibility with a wide range of rover&base stations
- 【Smart Handheld Collector】The SMA26 Plus GPS receiver is paired with an Android 11 handheld with 5.45" HD screen, dual SIM, 9000mAh battery, NFC, IP68 protection, dual-band RTK support, and 13MP rear camera
- 【All-in-One Integration】 The SMA26 Plus RTK GNSS receiver features built-in Bluetooth, UHF radio, WiFi, IMU, antenna, and 32GB of storage. It allows for easy switching between base station and rover modes with a single device
Single-base RTK and network RTK
Both approaches deliver real-time corrections, but they get them from different reference arrangements. The right choice depends on whether the site can support a suitable local base and, for network service, whether coverage and connectivity are available.
| Method | How corrections reach the rover | What the crew needs to consider |
|---|---|---|
| Single-base RTK | A physical base receiver at a stationary location broadcasts correction data to the rover. | The base must be stable, its coordinates must be suitable for the project, and the crew needs power, a correction link, and adequate radio range. |
| Network RTN/NRTK | A real-time network uses multiple reference stations to compute a virtual reference near the rover and sends corrections over a communications link. | Check local network coverage, cellular or other communications reliability, service terms, network integrity, and the coordinate frame in use. |
For network RTK, the rover connects to the service and sends an approximate position; the network calculates a virtual reference and returns corrections as if a nearby physical station were present. The USGS overview of RTN surveying notes that a network can remove the need to establish a local base and can provide network integrity monitoring. These advantages do not remove the need for local control checks or reliable communications.
Rank #3

- 【Centimeter RTK Performance】L1-Laser GNSS RTK support with1408-channel L1/L2 GNSS engine delivers 5-second initialization and centimeter accuracy under trees and urban canyons, supporting GPS/GLONASS/Galileo/BDS/QZSS/SBAS.
- 【Laser + GNSS Hybrid Survey】Our L1-Laser gps rtk has Integrated laser enables 10m non-contact measurement for inaccessible points such as powerlines and bridge edges while maintaining centimeter precision.
- 【120° Tilt Compensation】High-grade IMU supports ±60° tilt with auto-calibration, achieving 2cm accuracy at maximum tilt for faster, pole-free topographic surveys.
- 【15km UHF Radio】The L1 gps surveying equipment built-in 2W UHF transceiver provides up to 15km rover-base range and supports RTCM/CMR, compatible with third-party bases and CORS/NTRIP workflows.
- 【AR Stakeout】Paired with the handheld collector, SingularPad enables AR stakeout—overlaying virtual point guidance on the camera view for faster, intuitive field layout.
How to judge whether a rover point is trustworthy
A rover can report a consistent relative position while still being wrong for the job’s coordinate frame. For example, if the base coordinates are incorrect or are expressed in a different reference system from the project, the rover’s points may be shifted relative to the required control. Consider the full survey setup and field evidence, not just the receiver model or an accuracy figure.
- Correction status: Confirm the rover is receiving the intended corrections and has a usable solution before recording or staking a point.
- Reference and control: Verify that the base or network solution uses coordinates and a reference frame appropriate to the project. Check surveyed results against surrounding control points or benchmarks.
- Antenna and pole setup: Enter the correct antenna model and measure the pole or antenna height carefully. A height or model error affects the computed ground-point coordinates.
- Satellite visibility: Favor open sky. Buildings, deep cuttings, vehicles, towers, and tree canopy can obstruct signals or degrade observations; Trimble’s rover operation guidance identifies these as conditions to avoid where possible.
- Independent repeatability: Take redundant independent readings on selected points and compare them with control. The USGS recommends staying within the RTN, checking against surrounding benchmarks, calibrating the survey job when necessary, and taking redundant independent readings in its RTN surveying guidance.
- Operator review: Real-time positions can be harder to verify than static or rapid-static GNSS positions, so NOAA emphasizes operator attention in its RTK manual.
Relative precision and project-coordinate accuracy are not interchangeable. A tight repeat on one point shows consistency; a comparison to suitable known control helps reveal whether the coordinates fit the project frame.
Rank #4

- 【Full-Constellation, Fixed in Seconds】E1 gnss rtk achieves stable fixed solution rapidly, even in challenging environments like multipath, tree canopy, and city canyons.E1 is equipped with a high-precision GNSS engine for simultaneously tracking GPS, BDS, GLONASS, Galileo, QZSS, IRNSS & SBAS.
- 【RTK Corrections Service/CORS Requirement】The E1 rover must connect to an RTK corrections service or a Continuously Operating Reference Station (CORS). You can purchase a third-party RTK service account or set up a GSM base station to get an RTK FIX solution. Check if your location is covered by CORS; you may need to buy local CORS services.
- 【Over 20hrs Operation】With optimized charging safety and internal battery design, E1 gnss survey equipment offers over 20 hours of continuous operation on a single charge, with fast charging support via Type-C port.
- 【5 Kilometers】E1 RTK GNSS Surveying System with IMU has a long transmission distance, Radio range between the rover and the base can reach 5 kilometers (3.1miles). Also E1 can compatible with base stations of other brands in both Radio and CORS mode. Support RTCM v3/CMR correction data transmission.
- 【60° Tilt, 5s Initialization】Our rtk gps equipped with a new generation IMU module, E1 initializes in just 5 seconds and allows tilt measurements up to 60°, ensuring ±2.5cm accuracy for the entire work.
Rover equipment and correction links
A rover setup may combine the receiver, antenna, radio, and battery in a single smart antenna, or use a modular receiver with a separate antenna. Corrections may arrive through an integrated radio, a controller’s cellular modem, or an external phone connected by Bluetooth or cable. The appropriate configuration depends on the correction source, required mounting, site communications, and the crew’s field workflow.
Coordinate reference, antenna setup, and post-processing
The rover’s relative position must be tied to the coordinates and reference frame required by the project. This is a surveying-control issue as much as a receiver issue. In the United States, NOAA’s Online Positioning User Service (OPUS) can provide National Spatial Reference System coordinates from eligible survey GNSS data. For applicable static submissions, OPUS requires correct antenna selection and antenna reference point height. NOAA warns that selecting the wrong antenna can cause a height error as large as 80 cm and horizontal error up to 1 cm; local multipath, adverse atmospheric conditions, and user errors can also affect results. Details are on the NOAA OPUS page.
Best Value

- 【High Capability & Compatibility】 The SMA26 Pro is an full-constellation 4G RTK GNSS receiver with wide protocol compatibility, making it compatible with multiple RTK brands. Supporting PPP, PPK, and RTK technologies, it delivers versatile, high-precision performance for a wide range of surveying applications. It also supports setting up as CORS network base station
- 【High-Precision GNSS System】 The SMA26 Pro RTK GPS surveying equipment includes an SMA26 Pro Rover and Base RTK receiver, as well as an Android handheld device with pre-installed surveying software. It achieves an RTK horizontal accuracy of ±8mm and a tilt measurement accuracy of 2.5cm
- 【Tilt Compensation】 The SMA26 Pro GNSS RTK offers a tilt accuracy of up to 2.5 cm (at tilt angles ≤30°), after simple initialization, it is suitable for precise measurements in locations with limited signal or restricted space, and supports a maximum tilt measurement angle of up to 60°
- 【All-in-One Integration】The SMA26 Pro RTK GNSS receiver features built-in Bluetooth, UHF radio, 4G, Wi-Fi, an inertial measurement unit (IMU), an antenna, and 32GB of storage. A single device allows for easy switching between base station and rover modes
- 【Smart Handheld Collector】This SMA26 Pro RTK land surveying equipment features an Android 11 handheld unit with a 5.45-inch HD screen, dual SIM card slots, a 9000mAh battery, NFC functionality, IP68 protection rating, dual-frequency RTK support, and a 13-megapixel rear camera
OPUS is a U.S.-specific example, not a universal control service. Projects elsewhere should follow the relevant national geodetic control and reference-frame guidance. A crew can also record GNSS observations and process them after fieldwork rather than relying exclusively on a real-time solution; that workflow has its own observation, control, and processing requirements.
When GNSS rovers are and are not a fit
A rover is useful when the site has adequate satellite visibility, a suitable correction source, and control tied to the project coordinate system. It is not a substitute for checking the datum, validating control, or following the project’s survey procedures. On sites with obstructed sky or unreliable correction communications, the crew may need another measurement method or workflow. The receiver’s specifications alone cannot establish whether a coordinate is suitable for a particular construction decision.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.




