Windows Errors? Fix Them Before They Spread
Repair common Windows errors and clear accumulated junk for a smoother, more stable PC - no reinstall needed.Free scan · no reinstallOutdated Drivers Are Slowing You Down
One free scan finds every outdated or missing driver and matches the right update for your exact hardware.Free scan · exact hardware matchThe Lawnbot 400 is a manually driven, radio-controlled conversion of a gasoline push mower. Its deck is mounted in a welded carriage, two electric wheelchair motors provide tank steering, an Arduino-compatible controller converts RC receiver pulses to motor commands, and a separate fail-safe removes 24-volt motor power when the signal or safety switch is absent. Autonomy was proposed as a future extension, not documented as a working feature.
This is a high-risk fabrication project involving a rotating mower blade, high-current batteries, moving chains and remote operation. Build and test it only in a controlled, unoccupied area, with a positive way to stop the blade and drive system before anyone approaches the machine.
What the documented Lawnbot 400 actually is
J. D. Warren designed the Lawnbot 400 to mow a roughly one-acre yard with hills, dips and rocks while the operator stood away from the machine. The December 18, 2012 Make: Magazine project page (updated February 11, 2022) labels the build Hard and estimates three to five days. It removes the wheels and handlebar from a used gasoline push mower, suspends the mower deck in a custom metal carriage, and drives that carriage with two electric wheelchair motors.
The published machine is an RC vehicle, not an autonomous mower. GPS logging, ArduPilot, cameras, wireless links and obstacle sensors are mentioned only as possible future additions.
#1 Best Overall

- 30+ Guided Electronics Projects: Start with LEDs and build toward LCD1602 displays, RFID access, motion detection, distance sensing, motor control and environmental monitoring for STEM learning, coding clubs, classrooms and hobby projects
- 200+ Components Across 63 Types: Includes an ELEGOO UNO R3 controller, LCD1602, RC522 RFID, RTC, HC-SR501 PIR sensor, ultrasonic sensor, DHT11, GY-521, MAX7219, keypad, joystick, relay, SG90 servo, stepper motor, breadboard and more
- Begin Without Soldering: Pre-soldered modules, a solderless breadboard, organized storage case and small-parts box reduce setup time and help beginners move from lesson to lesson while keeping LEDs, ICs, wires and sensors easy to find
- Learn, Modify and Create: Program the ELEGOO UNO R3 board with Arduino IDE using the included PDF tutorial and example code, then adjust sensor thresholds, timing, display text and motor behavior to turn guided lessons into original projects
- Flexible Power and Project Setup: Includes a 9 V, 1 A power supply, breadboard power module, 9 V battery and USB cable to support controller, breadboard and module experiments without sourcing basic setup accessories separately
System overview and published specifications
| Item | Documented value or description |
|---|---|
| Control method | Manual hobby-RC transmitter and receiver |
| Controller | Arduino-style ATmega168 board; ordinary Arduino boards are also suitable |
| Drive | Two electric wheelchair motors with tank steering |
| Chain reduction | 17:65 sprocket ratio; selected because direct drive lacked torque |
| Motor supply | Two 12 V batteries in series for 24 V |
| Example carriage | 24 in wide × 48 in long × 18 in tall |
| Deck height | About 2–3 in above ground in the example |
| Reported travel speed | 5–10 mph in the 2012 Make: report; not an independent test and potentially too fast for mowing |
| Build estimate | 3–5 days, according to the 2012 project page |
Parts, materials and tools
Core parts
- Two electric wheelchair motors
- Two drive wheels with bearings and two caster wheels
- Sprockets and #25 roller chain
- A used gasoline push mower
- Angle iron, square tubing, flat steel, threaded rod, bolts and other frame stock
- Two 12 V batteries for the 24 V traction system
- RC transmitter and receiver with servo output
- Arduino-compatible ATmega168 hardware, or a standard Arduino board
- A bidirectional 24 V H-bridge, either a homemade MOSFET design or a commercial dual-channel unit
- A separate fail-safe board, 5 V relay and larger 60 A relay
- Fuse, power-distribution block, switches, wire, LEDs, resistors, capacitors, heat sinks and a cooling fan
Workshop equipment
- Drill or drill press, angle grinder and optionally a welder
- Dremel, measuring tape and level
- Voltage meter, wire strippers, electrical tape and soldering iron
- Ratchet set, Allen wrenches, pliers and screwdrivers
If you etch the controller PCB yourself, the documented process also uses a laser printer, iron, acetone and an etchant setup. Hydrogen peroxide and muriatic acid require chemical-resistant gloves, safety goggles and a procedure appropriate to the chemicals; a purchased board avoids that fabrication hazard.
Build the mechanical platform
1. Lay out the drive and frame
Start by removing the donor mower’s wheels and handlebar while retaining the engine and cutting deck. Build the carriage around the actual deck and the wheelchair motors rather than assuming a universal drawing: mower dimensions and mounting points vary.
Two long angle-iron runners form the sides. Square-tube crosspieces support the front casters, a threaded rod serves as the rear axle, and angle-iron risers with flat-steel braces stiffen the rear structure. Use slotted angle iron for the motor mounts so each motor can slide during sprocket alignment and chain tensioning.
Rank #2

- ELEGOO UNO R4 WiFi Control Board: Fully compatible with Arduino IDE and original Arduino shields. Features a 32-bit 48 MHz Renesas RA4M1 processor, USB-C, a 12 × 8 LED matrix, a Qwiic connector, built-in Wi-Fi and Bluetooth connectivity. Suitable for interactive STEM projects, it gives learners more room to progress from basic circuits to connected IoT projects
- Step-by-Step Tutorials for Beginners: Start with clear wiring diagrams and ready-to-run sample code, then advance through sensors, displays, motors, RFID, and wireless projects. Structured lessons reduce setup confusion and help beginners understand both how each circuit works and how to modify it
- 200+ Components with Practical Modules: Ultrasonic sensor, PIR motion sensor, RFID module, OLED display, keypad, joystick, relay, servo, stepper motor, DC motor and fan blade, temperature and humidity sensor, breadboard, jumper wires, LEDs, resistors, and more. Also compatible with your existing UNO R3 shields and projects
- Build Projects You Can Recognize: Equipped with professional online tutorials and step-by-step graphical manuals. Suitable for teens, beginners, hobbyists, educators, engineering students and electronics enthusiasts. The included parts support a progressive path from first coding exercises to maker prototypes without purchasing every module separately
- Organized Parts and Reliable Support: Each kit includes clearly listed components and beginner-friendly project resources to help users identify parts and start faster. ELEGOO provides responsive technical support for setup, programming, wiring and troubleshooting, ensuring you have a smooth learning experience
Make the two chain runs equal in length and align both sprocket pairs in the same plane. Unequal chain geometry or misalignment can make the machine pull to one side, throw a chain or overload a motor. The documented 17-to-65 reduction sacrifices wheel speed for the torque that direct drive could not provide.
2. Hang the mower deck
Suspend the deck level at its normal cutting height with four 1-inch angle-iron hangers attached through the mower’s wheel-shaft holes. Keep the deck approximately 2–3 inches above the ground in the documented arrangement and leave at least 1/2 inch for the front casters to rotate without striking it. Check clearance through the entire steering range before installing the blade-drive components.
3. Mount batteries and electronics
Wire the two traction batteries in series: connect the negative terminal of one battery to the positive terminal of the other with a heavy-gauge jumper. The remaining positive terminal feeds the fuse and power-distribution block; the remaining negative terminal is the 24 V return.
Rank #3

- All-in-One Starter Kit for Beginners: Part of the Powered by Arduino program, this kit includes an original Arduino UNO R4 WiFi, 300+ high-quality components, 50+ hands-on projects (30 basic, 13 fun, and 8 IoT), and 100+ free video lessons co-created with renowned educator Paul McWhorter. Designed for beginners ages 8+, it provides a complete, step-by-step path to learn Arduino, electronics, coding, and IoT. RoHS compliant for added safety and quality, it also makes a thoughtful gift for tech enthusiasts, students, and aspiring makers for birthdays, holidays, and special occasions
- Powerful Arduino Uno R4 WiFi Board: Upgraded from the Arduino Uno R3, the Arduino Uno R4 WiFi features a 32-bit processor, more memory, and built-in WiFi and Bluetooth, enabling connection to third-party apps for more interactive and practical projects.
- 300+ Components for Endless Possibilities: With 300+ components and sensors, this kit is perfect for portable projects. It features step-by-step tutorials, open-source code, and compatibility with other Arduino boards like Uno R3 and Nano, offering endless customization and learning opportunities.
- Engaging Projects for Every Skill Level: Featuring 50 projects (30 basic, 13 fun, 8 IoT) with IoT app integration like Arduino IoT Cloud , this kit supports Arduino C++ programming, making it perfect for students, teachers, and engineers to learn, code, and create at any skill level.
- Dedicated Support for Beginners: Alongside online resources and video tutorials, SunFounder provides technical support and troubleshooting forums to help beginners solve programming challenges with ease.
Warren used a third 12 V battery for the controller electronics so motor-current spikes would not disturb the logic and radio equipment. Sharing the main supply is possible, but a separate electronics battery provides that isolation. Mount the RC controller, H-bridge and cooling fan, distribution block, fail-safe board, relays, fuse and electronics battery on a protected plywood plate. Keep wiring away from chains, hot engine parts and the blade deck, and provide strain relief at every moving or high-current connection.
How the control electronics work
The transmitter sends pulse-position modulation (PPM) to the receiver. The Arduino reads those receiver pulses and generates pulse-width modulation (PWM) commands for the H-bridge. The H-bridge turns the Arduino’s 0–5 V control signals into up to 0–24 V drive power for forward and reverse motor operation.
Free tools Windows power users keep installed
One-click scans. No signup required.
The custom board is an Arduino-style ATmega168 breakout with an LM7805 5 V regulator, 16 MHz crystal, reset button, indicator LEDs and screw terminals. A normal Arduino board can replace it. The documented pin allocation is:
Rank #4

- LEARN ELECTRONICS AND CODING FROM SCRATCH: Start your maker journey or enhance classroom learning with the Arduino Starter Kit R4 – no prior experience required. Includes a printed project book and all components for 13 hands-on tutorials, as well as access to a growing repository of projects that will be added over time.
- POWERED BY THE ARDUINO UNO R4 WIFI BOARD: Discover modern connectivity and performance with the Arduino UNO R4 WiFi, featuring built-in Wi-Fi and Bluetooth and full compatibility with the Arduino ecosystem.
- CERTIFICATION VOUCHER INCLUDED: Once you’ve mastered sensors, motors, displays, and logic through the projects, take the official Arduino Fundamentals certification exam with the voucher that comes with your kit.
- BONUS DIGITAL RESOURCES: Register your kit online to unlock extra projects, multilingual lessons (Italian, German, French), and exclusive online content designed by the Arduino team.
- DESIGNED FOR LEARNING AND TEACHING: Ideal for classrooms, labs, or self-learners. Combine hands-on experiments with clear explanations and an AI coding assistant to support you as you grow.
| Arduino pins | Function |
|---|---|
| 5 and 9 | Left motor H-bridge forward/reverse inputs |
| 6 and 10 | Right motor H-bridge forward/reverse inputs |
Verify the actual H-bridge input labels, motor polarity and common grounds against your hardware before applying power. The source describes the pin mapping but does not provide a universal wiring diagram for every commercial controller.
Tank steering
Map the transmitter’s left and right stick commands to the two drive motors. Equal forward commands move straight; commanding the motors in opposite directions produces a zero-turn-radius pivot. If one side runs backward when it should run forward, correct the motor polarity or software mapping with the machine raised securely and the blade system disabled.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.Implement the independent fail-safe
The safety circuit is deliberately separate from the Arduino. A third receiver channel, operated by a transmitter switch, is read by a dedicated fail-safe controller. When the channel produces a pulse between 1,900 and 2,100 microseconds, the fail-safe energizes a 5 V relay that holds the larger 60 A relay open in the 24 V motor-power path. If the RC signal disappears or the safety switch is turned off, the channel reads LOW and motor power is cut until an acceptable signal returns.
Recommended Free Tools
Best Value
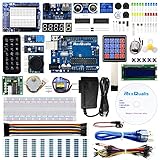
- The most economical kit comes with everything compatible with Arduino to starting programming for beginners .
- This is the upgraded starter kits come with a 9V 1A Power Adapter (At least $5.99 on amazon) to replace a 9V Battery , and the Lcd1602 module come with pin header(not need to be soldered by yourself).
- Include High Quality Base Board base on Arduino UNO R3 compatible with Arduino IED and Sensors, Servo, Motor, ULN2003 driver board, lcds, etc.
- Free PDF Tutorial and Datasheet are available to download from our official website or you can contact our customer service.
- All of the Components and Integrated Circuits are individually packaged and labeled, and packing in a plastic box which is bigger enough for you.
Keeping this function on a second controller preserves a layer of protection if the main Arduino freezes. Treat the fail-safe as a required power-interlock, not as a software convenience: test signal loss, transmitter switch-off and battery interruption before connecting the drive chains. The relay must interrupt the motor supply, not merely an Arduino input, and the fuse must be sized and installed for the actual wiring and controller.
A practical build and test sequence
- Survey the donor mower. Measure the deck, engine, blade clearance and wheel-shaft holes. Decide where the carriage can support the deck without interfering with the blade drive.
- Fabricate and brace the frame. Build the side runners, caster crosspieces, rear axle supports and motor brackets. Check that the frame sits level before tightening fasteners.
- Install the reduction drive. Fit the 17:65 sprocket pairs, slide the motors in their slots to align the chains, and set equal chain tension on both sides.
- Hang and level the deck. Use the four angle-iron hangers, check the cutting-height clearance and confirm that casters can rotate freely.
- Install electrical hardware with the blade disabled. Complete the 24 V series battery wiring, fuse and distribution block, then mount the electronics and route low-current and motor cables separately where practical.
- Program and verify the controller. Confirm receiver channels, PWM direction and the documented pin assignments. Test each motor briefly with the carriage supported and the cutting system unable to engage.
- Prove the fail-safe. With drive power available but the machine restrained, switch off the transmitter and operate the safety switch. The motor-power relay must drop out and remain out until a valid 1,900–2,100 microsecond signal returns.
- Conduct a slow-area trial. Use an empty, level test area first, then check steering, braking by removing drive power, chain retention, caster clearance, engine loading and radio range before attempting grass.
Operating limits and field reports
Make: reported a travel speed of 5–10 mph in 2012 and noted that this may be faster than ideal for mowing. Actual mowing speed depends on engine power, blade condition, terrain and grass; a low-cost mower engine can bog in tall or wet grass. Set a conservative control limit rather than assuming the published top speed is a useful cutting speed.
Warren also reported crossing a large hill and carrying a 155 lb person. That is the author’s field observation, not an independently controlled or safety-certified test, so it should not be used as a load rating or permission to carry passengers.
Choosing between the documented design options
| Decision | Advantages | Trade-off |
|---|---|---|
| Homemade MOSFET H-bridge and breakout PCB | Maximum learning, customization and repairability | More fabrication, heat management and wiring work |
| Commercial dual H-bridge and standard Arduino | Shorter build and less PCB fabrication | Less control over the power stage; ratings and cooling must match the motors |
| Dedicated fail-safe controller | Fault isolation if the main controller locks up | Extra board, relay and wiring |
| Single integrated controller | Simpler architecture | Loss of redundancy and less protection from a controller failure |
| Reduced drive | More wheel torque for starting and uneven ground | Lower wheel speed and additional chain maintenance |
| Shared battery supply | Fewer batteries and simpler charging logistics | Motor-current spikes can disturb control electronics |
| Separate electronics battery | Better isolation for radio and logic | Additional battery, charging and mounting requirements |
Can it be autonomous?
Not as documented. The Lawnbot 400’s proven control path is a human-operated RC transmitter, receiver, Arduino and H-bridge. Autonomous operation would require a new control and safety design incorporating position sensing, obstacle detection, reliable communications and a blade interlock; the cited project lists GPS logging, ArduPilot, cameras, wireless links and obstacle sensors only as ideas for future work. Do not describe an RC build as autonomous or operate it unattended.
Known evidence limits
The published project is a 2012 hobby build updated in 2022. It does not provide an independent laboratory performance study, safety certification, current component pricing or a current parts list. Historical prices from that article should not be treated as present-day costs, and every battery, relay, controller and motor must be checked against the ratings and condition of the parts you actually obtain.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.