Quick wins for a faster PC:
Clear out junk files and repair common Windows errorsFree Scan →Scan for outdated or missing drivers - takes under a minuteDriver Scan →Yes, you can still build the documented Hacker Shack “Follow Me” cooler, but not exactly as a current plug-and-play project. The 2017 design is a three-wheeled, GPS-guided robot built from a conventional cooler, wooden platform, Arduino Uno, two 12-volt geared motors, an L298N motor driver, GPS, compass, HC-05 Bluetooth, and a phone.
The mechanical platform remains a useful advanced robotics project. The original Blynk Bluetooth and GPS workflow is the major obstacle: Blynk IoT no longer provides the same Bluetooth connection and GPS Streaming features described in the original instructions. Plan to use legacy-compatible software, a replacement phone app, or a new network-based control layer.
As an Amazon Associate I earn from qualifying purchases.
What this cooler actually does
This is not a robot that visually recognizes and follows a person. It follows location coordinates supplied by a phone or travels toward programmed GPS waypoints.
Do these 3 things before closing this tab:
1Fix the driver behind crashes, sound loss and screen glitches2Repair Windows errors before they cause bigger problems3Scan for outdated or missing drivers - takes under a minute- GPS Streaming: the phone continually supplies its location, and the cooler attempts to follow those coordinates.
- GPS Waypoint: the robot travels toward predetermined coordinates.
The system compares the target location with the cooler’s GPS position and compass heading, then varies the left and right motor speeds. Phone GPS can wander by several metres, especially when the user is stationary, so the robot may turn unnecessarily, chase stale coordinates, or stop short of the target.
#1 Best Overall

- Keep Food Frozen, Drinks Ice Cold: Powered by a high-efficiency compressor, this 12V refrigerator cools from 68°F to 32°F in as little as 15 minutes and maintains temperatures from -4°F to 68°F. Switch between MAX mode for rapid cooling and ECO mode for energy-efficient operation, keeping food fresh and drinks cold wherever the road takes you
- Pack More for Every Adventure: The spacious 53QT car refrigerator capacity easily stores drinks, frozen food, meat, fruits, and snacks for camping, road trips, RV travel, fishing, and family weekends. Two removable baskets and a detachable divider help separate food and beverages for easier organization and quick access
- Power Anywhere Without Worry: Use your car fridge at home or on the road with included 110/240V AC and 12/24V DC adapters. Smart 3-level battery protection helps prevent vehicle battery drain, giving you confidence during long drives, camping trips, and overnight stops
- Quiet & Reliable Cooling: Designed for everyday travel, this electric cooler operates at only 45 dB for quieter performance and continues cooling on slopes up to 30° thanks to its anti-shake design. An easy-to-read LCD control panel lets you adjust temperatures with just a few taps
- Built for Easy Travel: Take your portable refrigerator anywhere with durable off-road wheels and a sturdy pull handle. Backed by EUHOMY's 2-year technical support, it's built for road trips, camping, truck driving, and everyday outdoor adventures
The original project was published on May 16, 2017. Its project page rates it as advanced and estimates approximately 10 hours of construction, although a modern reproduction can take substantially longer once software compatibility, calibration, and safety testing are included.
Quick verdict
| Question | Answer |
|---|---|
| Best for | Advanced makers, robotics students, and supervised outdoor experiments |
| Core navigation | Phone GPS, the robot’s GPS receiver, and a compass |
| True person-following? | No. It follows coordinates, not a person’s appearance or body position |
| Current software status | The original Blynk workflow needs legacy compatibility work or replacement software |
| Safe for unattended use? | No. The design has no documented obstacle avoidance or certified safety system |
System architecture
Phone GPS
   ↓
Bluetooth or replacement communication layer
   ↓
Arduino Uno
   ├── GPS receiver
   ├── Compass
   ├── L298N motor driver → left and right motors
   └── Servo → optional motorized lid
The two powered wheels form a differential-drive system. Both motors running forward move the cooler forward; reversing both moves it backward; changing the speed difference between the motors produces a turn. A swivel caster supports the third point of contact.
Parts list
Structure and running gear
- One cooler
- 1/4-inch MDF
- 1×2-inch and 1×3-inch lumber
- Two 6-inch wheels
- One swivel caster
- Two geared 12-volt DC motors
- Hardware, fasteners, wire, and cable
Control and navigation
- Arduino Uno
- L298N dual H-bridge motor driver
- Parallax PAM-7Q GPS module
- HMC-series compass module
- HC-05 Bluetooth module
- Breadboard and jumper wires
Power
- 2,200-mAh 3S 20C LiPo battery for the motors
- Separate portable USB battery for the Arduino and low-voltage electronics
- Appropriate charger, enclosure, fuse or resettable protection, and disconnect
Optional lid
- MG996R high-torque servo
- 3D-printed servo mount, hinged arm, and linkage parts
- Adhesive mounting tape and protected wiring
Check the exact sensor before ordering. The Hackster page uses inconsistent names, including HMC5833L and HMC6883L, while the repository references Adafruit_HMC5883_Unified. Identify the actual breakout board and its required library rather than assuming that similarly named compass modules are interchangeable.
Build the chassis
Measure your cooler first. The documented example uses a cooler bottom of approximately 17.5×11.5 inches and an MDF base of approximately 19.5×13.5 inches. The electronics box is approximately 11×9 inches.
The base is deliberately larger than the cooler. The extra clearance provides room for side rails, motor brackets, wiring, battery enclosures, and small cutting or measurement errors. Do not copy these dimensions blindly if your cooler has a different footprint.
- Cut the MDF base to suit the cooler and planned wheel spacing.
- Add 1×2-inch or 1×3-inch side rails to prevent the cooler sliding during acceleration and turns.
- Leave enough clearance for the motor brackets and rotating wheels.
- Mount the two powered wheels on opposite sides of the platform.
- Mount the swivel caster at the rear or opposite end of the drive axle.
- Create an electronics bay that keeps wiring clear of the wheels and caster.
- Secure the cooler without drilling into areas that could compromise its insulation or drainage.
The original design uses 3D-printed motor mounts, hub adapters, caster or idler mounts, servo mounts, and lid-actuator parts. The project links these files through a Hacker Shack Patreon post; access status should be checked before designing around a particular printed part.
Rank #2

- Fast, Stable Cooling: Powered by an advanced compressor, this electric cooler cools from 68°F to 32°F in about 15 minutes and maintains reliable temperature control. Keep drinks ice-cold and food fresh on road trips, camping, and long drives
- Large Capacity for Every Trip: Built for more than a few cans, the spacious 48QT interior of this car refrigetaror holds up to 46 standard 12 oz soda cans, plus meals, snacks, drinks, and frozen food for road trips, camping, and everyday travel. A removable basket keeps smaller items organized and easy to reach
- AC/DC Power Anywhere: Includes both 12/24V DC and 110/240V AC adapters, so you can power this 12 volt refrigerator in SUVs, pickups, RVs, or at home. Ideal for overlanding, fishing trips, and extra storage at home before your next adventure
- Low Power Use with Battery Protection: Choose ECO mode for energy savings or MAX mode for faster cooling, with average power consumption of just 45W. This car cooler runs as low as 45 dB and features three-level battery protection to help prevent vehicle battery drain during travel or overnight use
- Easy to Control, Easy to Carry: Adjust the temperature from the LCD panel or app. Move this car fridge easily with the sturdy handle, and find what you need at night with the built-in LED light. Backed by 2-year tech support for added peace of mind
Mechanical design considerations
A filled cooler is much heavier than an empty one. Starting torque matters more than unloaded wheel speed, and the caster may dig into grass, sand, or soft soil. A narrow platform can tip while turning or crossing uneven ground. MDF is also a poor unprotected material for an environment exposed to spills, condensation, and melted ice.
The Tool Desk
Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Use sealed or coated construction, raised electronics, protected cable exits, and a deliberate drainage strategy if the robot will operate near water. The original prototype should not be treated as waterproof.
Power architecture
The documented design separates the power domains:
- The 3S LiPo powers the 12-volt motors.
- A separate 5-volt USB battery powers the Arduino, sensors, and Bluetooth electronics.
- The grounds must be connected so the logic electronics and motor driver share a reference.
Do not assume that any USB battery can power the complete robot. Confirm the motor driver’s voltage and current limits, motor stall current, battery discharge capability, wire gauge, connector ratings, and fuse protection. Motor startup can cause voltage sag and electrical noise severe enough to reset the Arduino.
Keep the LiPo in a protected enclosure away from water and loose metal. Use a charger intended for the exact pack, inspect the battery for swelling or damage, prevent terminal shorts, and never charge it unattended. Add a master disconnect that can be reached without approaching the moving wheels.
Electronics and reference pin map
The repository’s reference configuration uses an Arduino Uno, L298N driver, HC-05 Bluetooth module, GPS, compass, and optional servo. These definitions are project-specific reference values, not universal wiring instructions:
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
#define SERVO_PIN 3

#define GPS_TX_PIN 6

#define BLUETOOTH_TX_PIN 10
#define BLUETOOTH_RX_PIN 11

#define MOTOR_A_EN_PIN 5
#define MOTOR_B_EN_PIN 9

#define MOTOR_A_IN_1_PIN 7
#define MOTOR_A_IN_2_PIN 8

#define MOTOR_B_IN_1_PIN 12
#define MOTOR_B_IN_2_PIN 4
The original configuration places the motor enable controls on PWM-capable pins. Verify the actual board, motor-driver labels, module voltage requirements, and library assumptions before copying the map. Low-cost breakout boards may label transmit and receive pins differently, and some modules require level shifting or other protection.
Rank #3

- Package Inclusions & 2 Year Tech Support; EUHOMY electric cooler is equipped with 100/240V AC and 12/24V DC adapters and can be used at home or in the car for a variety of use scenarios. The car refrigerator offers a 2 year tech-support. If you have any questions about our car fridge, please reach out to EUHOMY, and we will help you as soon as possible
- Powerful Compressor & APP Control; The compact and portable 12v cooler boasts a large 19Quart capacity. It can function as either a fridge or freeze. With an advanced compressor, the car cooler cools from 77°F to 32°F in just 15 minutes and consumes only 45W. With app control, you can conveniently manage the portable refrigerator from a distance to facilitate your journey
- Magnetic Sealing Design & Excellent Thermal Insulation; The 12v refrigerator's lid features a unique magnetic design that ensures a tight seal with the rubber gasket, enhancing insulation time and improving cooling efficiency. The magnetic opening cover of the portable fridge is designed for frequent use, ensuring convenience, durability, and reliability for your travels
- Battery Protection & Multiple Power Supplies; This portable freezer offers 3-level battery protection, allowing you to adjust the input power between L/M/H modes to prevent overload or vehicle battery drain. The 12 volt refrigerator can be powered by both DC and AC, making it suitable for various scenarios
- Silent & Anti-Shock Design; The 12 volt cooler operates with a low-noise cooling system, running at just 42 decibels, ensuring a peaceful and comfortable environment. Designed with anti-shock technology, this 12v fridge works smoothly even on bumpy roads with up to a 30 degrees incline
Keep the compass away from motors, the L298N board, steel fasteners, speakers, magnets, and high-current battery leads. The GPS antenna needs a reasonably unobstructed view of the sky and should not be buried inside a noisy electronics enclosure.
Compass calibration
The compass supplies the robot’s current heading. The software compares that heading with the direction toward the phone or waypoint. Calibration requires both local magnetic declination and correction for the compass’s mounting angle.
The repository includes these example values:
#define DECLINATION_ANGLE 0.23f
#define COMPASS_OFFSET 0.0f
Do not reuse them unchanged. Magnetic declination depends on location, while the mounting offset depends on how the sensor is physically installed. Mount the compass in its final position, keep the motors stopped, calibrate it away from steel and current-carrying wiring, and compare its heading with a phone compass. Then repeat the test with the motors running to detect interference.
Install and adapt the software
The repository lists these Arduino libraries:
- Adafruit Sensor
- Blynk
- Adafruit_HMC5883_Unified
The project source, README, parameters, and code are available in the official GitHub repository. Its reference values include:
#define MOTOR_A_OFFSET 20
#define MOTOR_B_OFFSET 0
#define GPS_UPDATE_INTERVAL 1000
#define GPS_STREAM_TIMEOUT 18
#define GPS_WAYPOINT_TIMEOUT 45
#define SERVO_LID_OPEN 20
#define SERVO_LID_CLOSE 165
These values illustrate the intended control strategy but are not universal settings. A motor offset may be needed because two nominally similar motors do not turn at the same speed. GPS and servo timing values should be tested with your hardware, surface, payload, and communication method.
The Blynk compatibility problem
The original instructions describe installing the code, uploading it to the Uno, waiting outdoors for GPS lock, pairing an Android device with the HC-05, entering Bluetooth password 1234 if requested, and pressing Play in Blynk. That is the historical workflow—not a guaranteed current setup.
Rank #4

- Dual-Zone Independent Control: This 12 volt refrigerator has 2 zones with separate temp control (-4°F to 68°F), preventing odor mixing and keeping food fresh. Easy-to-use control panel adjusts each zone simply. Perfects for truck/RV trips, boating, fishing, party—this electric cooler cools flexibly, meeting all your on-the-go needs, practical and convenient.
- 15 mins Fast Cooling & Low Power: The 12v cooler uses premium compressor tech, cooling from 77°F (ambient) to 32°F in 15 mins, down to -4°F in 45 mins. This car cooler has 3 modes—ECO saves energy, under 30W. Even Max (50W) uses far less than 1kWh/day with smart cycling.
- 45dB Low Noise & Anti-Shaking: This 12v freezer has 4 fixing holes on both sides, which can be firmly secured to the vehicle with ropes—staying stable even in 40° bumpy off-road conditions. The 45dB quiet technology ensures the 12 volt cooler won’t disturb driving or rest, keeping you safe and comfortable.
- User-Friendly Design: The 12v refrigerator includes a removable basket for easy storage organization, a bottom drain for quick cleaning, and built-in LED lights that auto-light in darkness. Its ergonomic handle and compact size make the portable fridge easy to carry and space-saving.
- Buy with Confidence: The car fridge equipped with 1* DC Cord, 1* AC Adapter, 1* User Manual and 1-year warranty.The 12V fridge features 3-level battery protection to prevent overload or vehicle battery drain, and is UL certified—ensuring uncompromised performance and safety during trips. Contact us with car fridge questions anytime.
A Blynk Community discussion reports that Blynk IoT removed the Bluetooth connection method and GPS Streaming widget. The repository also warns that streamed Blynk GPS coordinates were often inaccurate and suggests a dedicated Android app when greater precision is required.
Recommended Free Tools
Four practical software paths
- Legacy reproduction: preserve the original architecture with old-compatible software and libraries. This is useful for historical reproduction but may fail because old app flows, accounts, libraries, or Android behavior are no longer available.
- Custom Android app: read phone location and send latitude and longitude over Bluetooth. Add emergency stop, pause, resume, return, stale-data rejection, connection status, and GPS accuracy display. This is the closest modern replacement for the original design.
- Network-based control: send coordinates through a server, Wi-Fi, or cellular connection. This removes much of the HC-05 range limitation but adds latency, authentication, network dependency, maintenance, and possible service costs.
- New navigation stack: use an ESP32-class controller, better motor driver, wheel encoders, improved GNSS, and proximity sensors. This is a redesign rather than a drop-in update.
GPS limitations you must design around
GPS can take several seconds to acquire a fix outdoors. Phone GPS can wander even when the user is stationary, and a GPS receiver cannot reliably determine whether the phone is ahead, behind, or only a few metres away. GPS heading is also weak at low speed.
A robust implementation should stop when coordinates become stale, the phone disconnects, data is malformed, GPS accuracy exceeds a chosen limit, the compass reports an implausible heading, or the battery reaches its low-voltage cutoff. The repository’s timeout concepts are useful starting points, but they do not guarantee safe behavior in every failure mode.
GPS alone cannot detect curbs, stairs, people, pets, bicycles, vehicles, shorelines, or water. Test only in open, relatively flat spaces with direct supervision.
Independent reader supportYour contribution helps us test, update, and keep practical guides available for everyone.Test in stages
1. Bench test
- Lift the drive wheels off the ground.
- Test each motor independently and verify direction.
- Confirm the emergency stop or master disconnect.
- Check that the Arduino does not reset when motors start.
- Verify Bluetooth pairing and command reception.
- Confirm GPS serial data and compass readings.
- Move the servo through its range without forcing the lid.
2. Compass test
Calibrate in the final mounting position, compare against a phone compass, and repeat with motors running. If the heading changes dramatically when the motors operate, relocate the compass or redesign the wiring.
3. GPS test
Work outdoors with a clear sky view. Record stationary position drift, verify behavior when updates stop, and confirm that stale coordinates cause a stop rather than continued motion.
Best Value
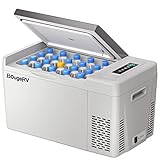
- What You Get: The CR22 12V refrigerator comes with a 2-year Tech Support. If you have any questions about the product, please REACH OUT TO BougeRV, as we provide friendly Tech Support. Package included: DC power cord, 6.56 ft AC power cord, and user manual
- Fast Cooling Down to 32℉: With Compressor refrigeration technology, this 12v car refrigerator could achieve 15 min fast cooling from 77℉ to 32℉ and 50 min from 77℉ to -5℉, keeping your food fresh. No ice needed, no food spoiled, money and space-saving. Dimension: 22.68*12.60*12.97 in, Weight: 22.27 lb, lightweight
- 60W Low Power Consumption: With ECO energy saving mode, this 23 Qt portable refrigerator's operating power is less than 45W. Even running on MAX mode(60W), it consumes far less than 1kWh/day for its intelligent cycle work. You can run this portable freezer fridge with 12/24V DC power on various vehicles, such as SUVs, Trucks, RVs, Camper, Van, Boat, etc
- 45dB Low Noise: The truck freezer is designed to run with low noise to make sure you have a good sleep after long driving. This camping fridge also has a shock-proof design to face the uneven road, operating with no problem in case of a 30 ° inclination when you are off-road
- 3 Level Voltage Battery Protection: The RV fridge/freezer is equipped with a 3-level battery monitor to prevent the fridge from draining your vehicle's battery. You can choose at what battery voltage the fridge shuts off to prevent complete battery drain
4. Low-speed drive test
Begin with an empty cooler in a large open area. Keep a person beside the robot with access to a physical cutoff. Test straight-line driving before turns, then test waypoint mode before GPS streaming.
5. Loaded test
Add weight gradually. Check motor and driver temperature, wheel slip, caster drag, frame flex, braking behavior, runtime, and battery condition on the surfaces where the cooler will actually operate.
Optional automatic lid
The motorized lid is separate from the navigation system and should be added only after the platform drives reliably. The documented version uses an MG996R servo, a 3D-printed hinged arm, servo mount, adhesive tape, a wiring hole through the cooler, and Arduino pin 3 for the signal.
The original builders found that the servo could not overcome the cooler lid’s snap notches and sanded them down. This is a mechanical issue, not simply a lack of servo power. A larger servo can damage the lid, linkage, or mounting point if the resistance and leverage are not corrected.
#define SERVO_LID_OPEN 20
#define SERVO_LID_CLOSE 165
Tune these endpoints for the specific cooler and linkage. Add pinch-point protection, strain relief, and sealing around any hole through the cooler. Keep the lid modification optional if simplicity and weather resistance matter more than convenience.
Troubleshooting
| Symptom | Likely causes | Recovery |
|---|---|---|
| Motors do not move | Incorrect driver wiring, missing common ground, insufficient current, disabled enable pins | Test each motor separately; verify motor supply, logic ground, enable pins, and battery capability |
| One motor runs backward | Reversed motor polarity | Swap that motor’s leads or invert its software direction |
| Robot veers | Unequal motors, wheel misalignment, caster friction | Apply motor offset, align the wheels, and inspect caster drag |
| Arduino resets when motors start | Voltage sag or motor noise | Separate logic and motor supplies, improve grounding, and add appropriate filtering and protection |
| Compass direction is wrong | Incorrect declination, mounting offset, or magnetic interference | Recalibrate in the final position and move the sensor away from motors and high-current wiring |
| GPS never locks | Indoor testing, obstructed sky, poor antenna placement, or defective module | Test outdoors, wait for acquisition, and inspect serial output and power |
| Following is inaccurate | GPS drift, stale updates, or outdated Blynk behavior | Stop on stale data and use a custom app or better positioning system |
| Bluetooth will not pair | Android compatibility, wrong baud rate, incorrect module mode, or obsolete app support | Confirm pairing mode, serial settings, module state, and whether the app still supports Bluetooth |
| Lid stalls | Snap notches, poor leverage, misalignment, or unsuitable servo endpoints | Reduce lid resistance, adjust the linkage, and tune endpoints without forcing the hinge |
| Robot continues after communication loss | Missing watchdog or stale-coordinate shutdown | Add local timeout logic, motor-driver shutdown, and a physical emergency stop |
Modernization roadmap
- Add safety first: physical emergency stop, master disconnect, watchdog, and local stale-data shutdown.
- Replace the obsolete app path: use a custom phone application or carefully designed network bridge.
- Improve motor control: replace the inefficient L298N with a suitable modern MOSFET-based driver after checking voltage and current requirements.
- Add wheel encoders: measure actual wheel movement instead of relying entirely on open-loop motor control.
- Add proximity sensing: ultrasonic, time-of-flight, or lidar sensors can help detect nearby objects, but they do not solve GPS drift by themselves.
- Improve localization: consider better GNSS or another localization method if the project needs repeatable position accuracy.
- Weatherproof the platform: replace or protect MDF, elevate electronics, use sealed boxes and cable glands, and separate electronics from meltwater.
When this project makes sense
Build it if you want an educational robotics platform, enjoy modifying Arduino hardware, can supervise low-speed outdoor tests, and accept approximate GPS navigation.
Do not use the original design unchanged around traffic, stairs, water, crowds, children, animals, or valuable cargo. It has no documented mapping, obstacle avoidance, visual person recognition, reliable close-range localization, or certified safety system.
The Bottom Line
The “Follow Me” cooler is still worth building as an advanced robotics and construction project, but treat the 2017 design as a starting platform. Reproduce the chassis and differential drive if they suit your goals, then replace the obsolete Blynk workflow, add local fail-safe controls, and test progressively. It can follow GPS coordinates in an open area; it cannot safely follow a person anywhere without supervision.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

