Yes—you can build a large FDM 3D printer around an Arduino Mega 2560, a RAMPS-style controller, and Marlin firmware. However, the Arduino is only the control system. The difficult parts are designing a rigid frame, supporting long motion axes, heating a large bed safely, and commissioning the machine without damaging hardware.
For a new build in 2026, use Mega/RAMPS when you want to learn, reuse parts, or keep costs low. For a serious large-format printer, a modern 32-bit Marlin-compatible controller is usually the better choice. Begin with a realistic build volume—approximately 300 × 300 × 300 mm to 500 × 500 × 500 mm—rather than starting with an enormous machine.
As an Amazon Associate I earn from qualifying purchases.
What an Arduino-based 3D printer actually does
An Arduino does not normally read an STL file and turn it directly into a print. The usual process is:
Recommended Free Tools
- Create or download a 3D model.
- Use a slicer to convert it into G-code.
- Send the G-code over USB, from an SD card, or through a host computer.
- Run Marlin firmware on the controller.
- Let Marlin coordinate motors, heaters, fans, endstops, temperature sensors, displays, and other hardware.
An official Arduino Mega 2560 Rev3 has 54 digital I/O pins, 16 analog inputs, four hardware serial ports, and 256 KB of flash memory. Those capabilities made it a practical foundation for the classic RAMPS architecture.
#1 Best Overall

- START CODING WITH THE ELEGOO UNO R3: Connect the included USB cable, upload your first sketch, and build sensor, motor, display, and automation projects, making it a practical controller for maker desks, classrooms, coding clubs, and robotics labs
- ATMEGA328P CORE FOR EVERYDAY PROJECTS: A 16 MHz clock, 32 KB flash, 14 digital I/O pins with 6 PWM outputs and 6 analog inputs provide a versatile foundation for LEDs, buttons, relays, servos, displays and sensors
- RELIABLE USB PROGRAMMING AND CLEAR WIRING: The ATmega16U2 USB interface supports sketch uploads and serial communication, while clearly labeled headers help simplify connections to jumper wires, shields and modules
- POWER AND EXPAND YOUR WAY: Run the board from USB or a recommended 7-12 V external supply, then add compatible shields and modules for data logging, automation, robotics, test fixtures and custom electronics projects
- BOARD AND USB CABLE INCLUDED: Comes with 1 ELEGOO UNO R3 development board and 1 USB-A to USB-B data cable; breadboard, sensors, shields and power adapter are not included, and younger learners should work with an experienced adult
Start with a design specification
Define the machine before buying components. Write down:
- Usable build volume: X × Y × Z in millimeters.
- Materials: PLA, PETG, ABS/ASA, TPU, nylon, or filled filament.
- Maximum nozzle and bed temperatures.
- Open, enclosed, or actively heated chamber.
- Target nozzle diameter, layer height, speed, and acceleration.
- Maximum object weight.
- Available electrical supply and workshop space.
- Door, ceiling, floor-loading, and service-access limitations.
A large open printer intended for PLA is a very different machine from an enclosed printer intended for ABS or engineering materials. “Big” means build volume, not merely the outside dimensions of the frame.
Choose the mechanical architecture
| Architecture | Advantages | Large-machine concerns |
|---|---|---|
| Cartesian | Simple motion model and easy calibration | A moving bed becomes heavy and unstable as it grows |
| CoreXY | Works well with a fixed bed and moving gantry | Requires accurate belt routing, a square frame, and equal belt tension |
| H-bot | Simple-looking belt arrangement | Can rack under uneven loads unless the gantry is exceptionally stiff |
| Delta | Fast and compact in some applications | Tall towers are difficult to keep rigid and require more calibration |
| Industrial-style gantry | Suitable for very large machines | Higher cost, stronger motors, and possibly external drivers are required |
For a first large home build, choose a fixed heated bed with a rigid Cartesian gantry or CoreXY motion system. Avoid a large moving bed unless you have specifically calculated its mass, acceleration, support, and vibration.
Build a rigid frame and motion system
Frame
Use T-slot aluminum extrusion, welded steel, or another structural system that can remain square under load. Add corner bracing or triangulation, adjustable feet, a flat base, and mechanical locating features that let you square the frame repeatedly.
Long unsupported extrusions, thin sheet material, loose furniture panels, and decorative enclosure panels are not substitutes for structure. Firmware cannot compensate for a flexible frame.
Linear motion
V-wheel extrusion systems are affordable and accessible, but they depend on accurately aligned extrusion and correctly adjusted wheels. Supported round rails tolerate larger spans better than unsupported rods. Profile linear rails generally offer better stiffness and repeatability, but they cost more and must be installed carefully. OpenBuilds is one source for V-Slot and C-Beam extrusion, belts, pulleys, and related motion hardware.
Use belts for fast X/Y motion and lead screws or suitable actuators for Z. Long belts can stretch and vibrate; very large axes may require wider belts, shorter belt paths, dual motors, or rack-and-pinion drives.
The Tool Desk
Outbyte Driver Updater FREEFix the driver behind crashes, sound loss and screen glitchesFind Drivers →Outbyte PC Repair FREEClear out junk files and repair common Windows errorsFree Scan →Z axis and gantry support
A wide gantry or large bed usually needs two or more Z screws or actuators. They may be mechanically linked, electronically synchronized, or independently driven by firmware that supports reliable gantry leveling. Use appropriate thrust bearings, couplers, and anti-backlash hardware where necessary. One long lead screw may sag, whip, or twist and is not automatically adequate for a wide machine.
Rank #2

- ATmega328P Microcontroller: Powered by the reliable ATmega328P, running at 16 MHz with 32KB of flash memory, 2KB SRAM, and 1KB EEPROM, offering ample resources for a wide range of basic to advanced electronics projects.
- 14 Digital I/O Pins & 6 Analog Inputs: Features 14 digital I/O pins (6 of which support PWM output) and 6 analog inputs (10-bit resolution), providing flexible options for sensors, motors, and other external components.
- USB Connectivity for Easy Programming: The built-in USB port allows for direct programming and serial communication, enabling a simple connection to your computer for sketch uploading and debugging through the Arduino IDE.
- Compatible with Arduino IDE: Full compatibility with the Arduino IDE ensures easy access to a vast array of libraries, code examples, and community-driven projects, making the Uno a great choice for both beginners and experienced makers.
- Widely Used in Education & Prototyping: The Arduino Uno is a standard in educational environments, widely used for learning and teaching electronics and programming. It's perfect for prototyping, robotics, IoT projects, and more.
Select the electronics
Mega 2560 and RAMPS
The classic arrangement consists of:
- Arduino Mega 2560.
- RAMPS 1.4 or a compatible RAMPS board.
- Plug-in stepper-driver modules.
- Endstops and thermistors.
- Hotend and bed heater outputs.
- Fans and, optionally, an LCD/SD controller.
RAMPS 1.4 is an older design, and clone quality varies. A board labelled “RAMPS 1.4” may have different MOSFETs, screw terminals, fuses, copper weight, and quality control from another clone. Its integrated outputs may also be unsuitable for a high-current bed, multiple heater zones, or several large motors.
The Mega is reasonable for an educational or recycled-parts build. For a new, high-current, high-speed, or very large machine, select a modern 32-bit board from the supported options in Marlin’s controller-board documentation. You get more processing and memory headroom and often better driver, sensor, expansion, and connectivity options.
Motors and drivers
Do not select motors solely by their NEMA size. Calculate torque for the moving mass, belt or screw pitch, acceleration, and required speed. A large printer may exceed what small NEMA 17 motors and plug-in A4988 or DRV8825 modules can comfortably handle. External drivers may be appropriate for larger motors, but their voltage, current, step/dir interface, enable logic, and fault behavior must match the controller.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Design the hotend and heated bed
Extrusion
Choose the hotend for the required melt flow, not just its maximum temperature. Consider direct drive versus Bowden, standard filament versus pellet extrusion, nozzle diameter, heater rating, thermistor or thermocouple type, heat-break rating, cooling, and filament-path support.
A larger nozzle can shorten print times, but it also requires more melt flow and extrusion force. It produces more visible layers and makes poor leveling more consequential. Pellet, clay, concrete, and paste extrusion require different pumps or augers, nozzles, cleaning procedures, and structural calculations; they are not simply oversized filament printers.
Bed design
A large bed must remain supported, flat, uniformly heated, and safe. Plan for thermal expansion, insulation, a removable build surface, temperature sensing, and an adequate support structure. Multiple heater zones can improve uniformity but add wiring and control complexity.
Never connect a high-current bed heater directly to an Arduino output. Use correctly rated switching hardware, fuses, wiring, terminals, strain relief, and an enclosure. Mains-powered heaters require appropriate grounding, overcurrent protection, enclosure, and compliance with local electrical rules; improvised mains wiring is not a beginner procedure.
Free tools Windows power users keep installed
One-click scans. No signup required.
At 24 V, current is calculated as:
I = P ÷ V
A 600 W heater would draw approximately 25 A before losses and startup effects. That is far beyond an Arduino pin and may exceed an underspecified connector, MOSFET, fuse, or wire.
Rank #3

- START CODING WITH A FLEXIBLE UNO R3 BOARD: Connect the included USB cable, upload sketches with Arduino IDE and build sensor, motor, display and automation projects for maker desks, classrooms, coding labs and electronics prototyping
- ATMEGA328P CORE FOR EVERYDAY PROJECTS: A 16 MHz clock, 32 KB flash, 2 KB SRAM, 1 KB EEPROM, 14 digital I/O pins with 6 PWM outputs and 6 analog inputs support LEDs, buttons, relays, servos, displays and sensors
- CH340C USB-TO-SERIAL INTERFACE: The onboard CH340C handles USB communication for sketch uploads and serial monitoring, while clearly labeled digital, analog and power headers help simplify wiring to modules and shields
- USB OR EXTERNAL POWER: Run the board from the included USB cable or a recommended 7-12 V external DC supply, then expand with compatible shields and modules for robotics, data logging, automation and custom embedded projects
- BOARD AND USB CABLE INCLUDED: Comes with 1 ELEGOO UNO R3 controller board and 1 USB-A to USB-B data cable; breadboard, jumper wires, sensors, shields and power adapter are not included
Calculate the power system
Estimate the continuous load before selecting a supply:
Ptotal ≥ Pbed + Photend + Pmotors + Pfans + Pelectronics
Add engineering margin and account for startup and sustained heating. Include the correct supply voltage, fuses or circuit breakers, protective grounding and bonding, suitable terminals or ferrules, enclosed connections, cable strain relief, and an emergency-stop or power-disconnect strategy.
Quick wins for a faster PC:
Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →Repair Windows errors before they cause bigger problemsFix Now →USB and logic power are not the same as heater and motor power. The RAMPS documentation warns that the Mega’s barrel connector does not power the stepper motors, heated bed, or other high-power loads: RAMPS power documentation.
Wire the printer in stages
- Mount the controller where it is ventilated and insulated from the frame.
- Install stepper drivers in the correct orientation.
- With power removed, connect motors.
- Connect endstops, checking signal, ground, and voltage pins against the board documentation.
- Connect thermistors and fans.
- Connect the hotend heater.
- Connect the bed heater through correctly rated switching and protection hardware.
- Check polarity, continuity, connector ratings, loose strands, shorts, and exposed conductors.
- Power the logic system first where the design permits.
- Test sensors before enabling heaters.
- Test motors briefly at low speed.
- Test heaters while monitoring temperature and current.
- Install covers, strain relief, and cable management before routine operation.
Endstop connector order varies. Verify the board labels and schematic rather than trusting a photograph or generic cable; see the RAMPS connector guidance.
Install and configure Marlin
Marlin’s current preferred build workflow uses PlatformIO and Auto Build Marlin. Download Marlin, begin with the closest official example configuration, edit the configuration, build, and upload the correct target. The current process is documented at Marlin installation. Arduino IDE remains relevant for some AVR and legacy targets, but current board support may require PlatformIO: Marlin’s Arduino IDE guidance.
Configure these categories for the actual machine:
- Board and pin mapping.
- Build geometry and software limits.
- Axis direction and endstop locations.
- Steps per millimeter, feedrates, and acceleration.
- Extruder count and extrusion settings.
- Thermistor types and heater limits.
- PID temperature control.
- Thermal protection.
- Homing and bed-leveling behavior.
- Mesh size, display, SD, filament runout, and power-loss features if fitted.
For a hypothetical 500 × 500 × 500 mm usable volume:
#define X_BED_SIZE 500
#define Y_BED_SIZE 500
#define Z_MAX_POS  500
These are examples only. They must describe the nozzle’s actual reachable envelope, not merely the bed or frame size.
Rank #4

- TURN CODE INTO REAL-WORLD RESULTS — Follow 22+ guided lessons to make LEDs blink, read temperature and distance, move servo and stepper motors, control an LCD and respond to joystick or IR input; ideal for a family weekend build, homeschool unit, coding club or STEM classroom
- MORE PROJECT VARIETY IN ONE ORGANIZED KIT — Includes the UNO R3 controller, LCD1602 with pre-soldered header, breadboard power module, ultrasonic and DHT11 sensors, joystick, IR receiver and remote, SG90 servo, stepper motor, relay, DC motor, fan blade, displays, LEDs, buttons, resistors and jumper wires
- START WITHOUT SOLDERING — Plug-in modules, a solderless breadboard and the pre-soldered LCD help beginners focus on wiring, code and testing; the illustrated component list makes it easier to find each part and move from one lesson to the next
- LEARN THE LOGIC, THEN CREATE YOUR OWN — Use Arduino IDE and the included example code to understand digital input and output, analog sensing, timing, motor control and display functions, then change thresholds, speeds and sequences for alarms, environmental monitors, reaction games and motion projects
- CLEAR SETUP SUPPORT FOR FIRST-TIME BUILDERS — Download the latest tutorial and code, select the UNO board and correct computer port, check component polarity and breadboard rows, and keep power-module input at 9V or below; younger learners should work with an experienced adult
For a belt axis:
steps/mm = (motor steps/revolution × microsteps) ÷ (belt pitch × pulley teeth)
For a lead screw:
steps/mm = (motor steps/revolution × microsteps) ÷ screw lead
Calculate an initial value, then calibrate the completed machine. Never copy PID values, thermistor settings, acceleration, or motor current from another printer without verifying the hardware. Marlin identifies thermal protection as a critical safety feature and documents protection against failed heaters, disconnected sensors, and thermal runaway: Marlin configuration documentation.
Do these 3 things before closing this tab:
1Fix the driver behind crashes, sound loss and screen glitches2Clear out junk files and repair common Windows errors3Scan for outdated or missing drivers - takes under a minuteCommission the machine before printing
Sensor and safety checks
- Confirm the controller boots.
- Check that every thermistor reports a plausible room temperature.
- Confirm heaters are off when commanded off.
- Verify fans and endstops.
- Confirm the emergency-stop or power-disconnect procedure.
- Ensure the nozzle cannot strike the bed or frame.
Useful commands, subject to your Marlin configuration, include:
M115                 ; Firmware information
M503                 ; Stored settings, where supported
M105                 ; Temperature readings
M119                 ; Endstop states
G28                  ; Home configured axes
G1 X100 Y100 Z10 F3000 ; Low-risk test move
M104 S200            ; Set hotend temperature without waiting
M109 S200            ; Set hotend temperature and wait
M140 S60             ; Set bed temperature without waiting
M190 S60             ; Set bed temperature and wait
M84                  ; Disable steppers
M112                 ; Emergency stop
Motion tests
- Move each axis 10 mm at low speed.
- Confirm direction and measure actual travel.
- Correct direction in firmware or wiring with power removed.
- Test again at slower and faster speeds.
- Verify endstop states before homing.
A wrong direction or incorrect endstop state can cause a hard collision. Never hot-plug stepper motors; doing so can damage drivers.
Extruder calibration
Heat a conventional hotend to its normal extrusion temperature. Mark a known filament distance, command a measured extrusion, measure the actual movement, and adjust extruder steps/mm. Recheck after changing the extruder, gear ratio, or firmware. Do not cold-extrude a conventional hotend unless its manufacturer explicitly permits it.
Bed calibration and PID
First mechanically tram the bed, align the gantry, and synchronize Z screws. Then use mesh leveling or a probe if installed. Account for thermal expansion by checking the bed at operating temperature. A probe maps surface variation; it cannot repair a loose gantry or an unpredictable bed.
Tune hotend and bed PID only after the heater, sensor, wiring, fan arrangement, enclosure, and power supply are secure. Record the values and retest after changing those conditions.
Best Value
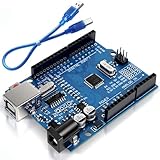
- Unlock your creativity with the versatile UNO R3 Board ATmega328P! Explore endless possibilities in electronics projects with its user-friendly Arduino development environment, extensive digital and analog I/O pins, and compatibility with various sensors and modules. Let your imagination soar!
- Experience the power of UNO R3 Board ATmega328P! This feature-packed development board boasts a high-performance ATmega328P microcontroller, 32KB of flash memory, and 2KB of SRAM. It's perfect for both beginners and advanced users seeking to build innovative applications in robotics, home automation, and more.
- Ignite your passion for electronics with the UNO R3 Board ATmega328P! Its open-source design allows for customization, while its 14 digital I/O pins and 6 analog input pins provide ample connectivity options. Get ready to bring your ideas to life and create interactive projects like never before.
- Elevate your DIY projects with the UNO R3 Board ATmega328P! This highly versatile development board offers seamless integration with the Arduino ecosystem, providing access to a vast library of code and resources. With its reliable performance and broad compatibility, you can easily prototype and realize your electronic dreams.
- Discover the endless potential of the UNO R3 Board ATmega328P! With its robust communication interfaces, including UART, SPI, and I2C, you can connect and communicate with a wide range of devices. Whether you're a hobbyist or a professional, this powerful development board is a must-have for creating innovative and interactive electronic systems.
Set realistic slicer limits
A larger printer is not automatically faster. Productivity usually comes from a larger nozzle, sensible layer height, adequate melt flow, and reliable motion—not simply higher XY speed.
Set and test:
- Nozzle diameter, line width, and layer height.
- Volumetric flow limit.
- Retraction and travel speed.
- Acceleration and cooling.
- Brim or raft strategy.
- Adhesion and material-specific temperatures.
- Maximum object size after skirts, brims, purge lines, and clips.
Long prints add exposure to warping, layer separation, power interruptions, filament tangles, clogs, thermal drift, vibration, and accumulated positioning errors. Start with small test parts across the entire bed before attempting a multi-day print.
Common problems and recovery
Firmware will not compile
Confirm the board environment, start from a matching official example configuration, check that the Marlin version and configuration package match, and disable features that exceed the board’s memory. Use the PlatformIO error output rather than guessing at library versions.
Outdated Drivers Are Slowing You Down
One free scan finds every outdated or missing driver and matches the right update for your exact hardware.Free scan · exact hardware matchPC Slower Than It Used to Be?
A free scan shows the junk files, broken settings and background clutter dragging Windows down - then fixes them in one click.Free scan · Windows 10 & 11Firmware uploads but the printer resets
Disconnect slicer or host software that may hold the serial port. Check the USB cable and power, verify the selected port, look for brownouts when motors or heaters start, and inspect for shorts in endstops, fans, heaters, or thermistors.
The display shows MINTEMP
Inspect the thermistor connector and wires, confirm the thermistor type, and verify that the sensor is mounted correctly. Do not bypass the error merely to make the printer heat.
Heating failed or thermal runaway
Stop the machine and switch off power. Inspect heater attachment, thermistor contact, wiring, airflow, and PID values. A fan may be cooling the block unexpectedly. Resolve the physical fault before retuning PID, and do not disable thermal protection as a routine fix.
Motors skip or stall
Reduce speed and acceleration first. Then check driver current, binding rails, screw alignment, gantry racking, belt tension, motor torque, and power-supply voltage drop. Increasing driver current without finding the mechanical cause can overheat the motor or driver.
The first layer is uneven
Check frame and gantry alignment, bed support, Z synchronization, thermal expansion, probe repeatability, and mesh settings. Auto bed leveling cannot compensate for structural looseness.
Arduino Mega or modern 32-bit control?
| Choose Mega 2560 + RAMPS when… | Choose 32-bit control when… |
|---|---|
| You are learning electronics or reusing existing parts. | You are starting a new serious large-format build. |
| The machine is modest and uses conservative motion settings. | You need more processing headroom, modern drivers, or expansion. |
| Legacy RepRap compatibility matters. | The machine has multiple motors, heaters, probes, or advanced features. |
For a low-risk learning project, use a modest fixed-bed printer, standard filament, conservative speeds, and carefully protected power electronics. For the best new-build value, use a rigid fixed bed, supported motion, a 24 V system, a capable hotend, and a smaller volume than your first instinct suggests. For a genuinely large home machine, plan for synchronized Z, heavy bracing, zoned heating, external drivers where needed, and electronics outside a heated chamber.
Also compare the complete project with buying a proven smaller printer. Tools, failed parts, machining, wiring, enclosure work, and development time can make a DIY machine more expensive than expected. Build the large printer because you want the engineering project—not because the Arduino alone makes it cheap.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.

