Some links on this page are affiliate links: if you buy through them we may earn a commission, at no extra cost to you.
A DIY pick-and-place machine using OpenBuilds hardware and a Smoothieboard is possible, but the documented design is a project reference—not a complete kit or guaranteed construction plan. John deGalvina’s machine combined an OpenBuilds frame, a Smoothieboard-derived controller, OpenPnP, vacuum pickup, feeders and dual-camera vision. Its builder reported about 1,200 parts per hour after switching from Ethernet to USB serial; that is a result from this particular build, not a verified performance specification. The project log and OpenBuilds listing are useful architectural references, but a new machine still needs mechanical design, wiring, firmware configuration and calibration.
What the documented machine is
The Hackaday.io project, “Pick and place machine – Smoothieboard/OpenPnp,” is a dual-head surface-mount assembly machine built around OpenBuilds hardware and OpenPnP software. The project listing describes a Smoothieboard 5X assembled from a 4X board, 3D-printed 0816 automatic feeders, a material stack block, a dual head with linear rails, dual-camera vision, and both automatic and drag feeders. Those are details of the builder’s implementation, not a universal bill of materials. Hackaday.io project
Hackster’s coverage identifies V-Slot Mini V linear-actuator and gantry hardware, NEMA 8/17 motors, Juki nozzles, a USB microscope and a Teslong inspection camera. It also repeats the builder’s approximate 1,200-parts-per-hour result after changing communications from Ethernet to USB serial. That figure is builder-reported and should not be treated as a guaranteed rate or a measure of placement yield. Hackster coverage
The Tool Desk
Outbyte Driver Updater FREEScan for outdated or missing drivers - takes under a minuteDriver Scan →Outbyte PC Repair FREERepair Windows errors before they cause bigger problemsFix Now →What the machine must do
A pick-and-place machine is more than a CNC gantry with a pump attached. For each component, it must reach a feeder, pick up the part without shifting it, determine its position and rotation, align that part to the PCB design coordinates, place it at a controlled height and release it cleanly. The control software must coordinate those actions with cameras, feeders, board registration and the motion controller.
#1 Best Overall
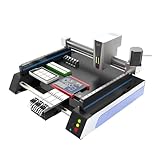
- Triple Vision Camera System:Equipped with three high-speed cameras, including dual bottom cameras for fast shooting. Supports recognition of various marks (solder pads, circles, vias, screen printing) and mark-free mode, ensuring precise component alignment and placement.
- Efficient High-Speed Performance:Adopts advanced S-curve motion control, 80% faster than similar models with max speed up to 3000 points per hour. Stable vibration and fully automatic operation greatly improve throughput for prototype and small-batch production.
- Automatic Head Replacement & Versatile Feeders:Dual mounting heads support passive automatic head change with up to 6 nozzle libraries for one-time mounting of diverse components. Compatible with visual bulk, automatic, manual and tray feeders; Feida supports code-scanning adding for efficiency.
- Stable Integrated Structure:Features sheet metal integrated welded body, avoiding loose aluminum profile structures. Built-in high-power suction nozzle motor with all-metal gears. Whole machine shipped ready to use, durable and compact.
- Wide Compatibility & Desktop Design:Supports 220V dual voltage for global use. Ideal for various SMD components including LEDs. Space-saving desktop design is perfect for labs, workshops and small-scale electronics manufacturing.
- Move the nozzle to a feeder or tray and lower it to the pickup height.
- Switch on vacuum, lift the component and verify pickup if a vacuum sensor is fitted.
- Inspect the part using an upward-looking camera or another configured vision arrangement; correct its X, Y and rotational offset.
- Use board coordinates and fiducials to locate the placement point.
- Lower the part, release vacuum, and use a controlled vent or brief air pulse if the system requires it.
- Retract the nozzle and proceed to the next placement.
OpenPnP provides software for machine configuration, feeders, cameras, nozzles and board-placement workflows. Its hardware directory shows a broader ecosystem rather than one prescribed machine design. OpenPnP hardware
Choose a manageable machine architecture
A practical first layout is a fixed PCB bed and fixed feeder bank under a moving overhead XY gantry, with a lightweight Z/nozzle head. A fixed bed keeps the board fixture, feeder locations and camera references stationary relative to one another. A moving PCB platform can reduce gantry travel in some designs, but complicates registration and the relationship between feeders and board.
| Subsystem | Typical role | Design consideration |
|---|---|---|
| Frame | Supports the bed, gantry, feeders and cameras | Extrusion is modular, but frame squareness and stiffness determine usable repeatability. |
| X/Y motion | Moves the head between feeder, vision and board positions | Belts suit lightweight, faster travel; wheels or rails must be aligned and maintained. |
| Z motion | Controls pickup and placement height | A guided or screw-driven axis can help control nozzle height. |
| Rotation | Turns the component to its board angle | Must be configured as a real rotary axis in both controller and OpenPnP. |
| Vacuum and nozzle | Pick up and release parts | Nozzle size, leaks, valve response, tubing and component geometry all matter. |
| Feeders | Present parts at known pickup coordinates | Begin with trays or passive cut-tape holders; automatic feeders need reliable indexing. |
| Cameras and software | Correct part and board coordinates | Camera offsets, focus, lighting, axis conventions and fiducials require calibration. |
OpenBuilds mechanics: useful, but not precision by default
OpenBuilds extrusion, gantry plates, wheels, actuators, belts and fasteners make a modifiable frame that can be adapted with custom brackets and printed feeder parts. But general-purpose motion hardware is not purpose-designed SMT equipment. V-wheel preload, dust, belt tension, extrusion alignment and gantry flex can all affect repeatability. A frame that looks rigid may still deflect when the nozzle touches a feeder or accelerates across the work area.
Belts are a reasonable choice for a lightweight X/Y head. A guided screw-driven Z axis can help with controlled vertical movement, though screws introduce their own alignment and backlash concerns. Linear rails can improve guidance and stiffness, but they cost more and demand careful mounting; rails cannot correct a twisted or out-of-square frame. The original project used OpenBuilds hardware and linear rails at the dual head, but does not establish one official dimensioned frame plan. OpenBuilds project listing
Start with one head unless throughput justifies two
The original machine used a dual surface-mount head and Juki nozzles. A second head can reduce nozzle changes or support different package ranges, but it adds mass, vacuum routing, collision risk, offsets and calibration work. A single head is the more manageable first milestone for most builders. Keep nozzle rotation as a separately tested axis; do not assume it behaves like a printer extruder.
Define requirements before buying parts
Pick-and-place difficulty rises sharply as component size shrinks and geometry becomes more demanding. A machine aimed at 1206 passives and SOIC packages is a substantially easier project than one expected to handle 0201 parts, QFNs or fine-pitch BGAs. Write down the intended operating envelope first:
Rank #2

- SMT802A-S Automatic Low Price Pick and Place Machine Small Desktop LED Production Machine
- Maximum PCB dimensions and how the board will be clamped.
- Smallest and largest component packages, including component height.
- Number of feeders and whether tape reels must be supported.
- Required placement accuracy, first-pass success and useful throughput.
- Whether one or two cameras, multiple nozzles or automatic feeders are actually needed.
- Available bench space, electrical supply, noise tolerance and guarding.
These choices determine the frame size, head mass, camera arrangement, nozzle selection and feeder strategy. Do not buy a large collection of automatic feeders before the machine can reliably home, move, pick and place from one known location.
Quick wins for a faster PC:
Clear out junk files and repair common Windows errorsFree Scan →Fix the driver behind crashes, sound loss and screen glitchesFind Drivers →Controller and Smoothieware configuration
The source project used a Smoothieboard 4X-derived setup and was described as a Smoothieboard 5X. For a new build, verify the exact board revision, firmware and available drivers before wiring or copying settings. Smoothieboard V1 documentation describes five stepper-driver positions on the 5X, Allegro A5984 drivers, six endstop inputs, configurable microstepping and current, and motor voltage up to 35 V. The listed 2 A continuous driver capability is conditional on thermal conditions; it is not a recommended setting for every motor. Smoothieboard V1 specifications
Smoothieware maps G-code axes to internal names: X to alpha, Y to beta, Z to gamma, A to delta, B to epsilon, and C to zeta. A rotation axis therefore consumes a configured axis and must use the same axis, units and direction assumptions in the controller and OpenPnP. Smoothieware basics and six-axis configuration
Check V1 versus V2 syntax
Do not paste a configuration example until the controller generation and firmware format are known. Smoothieware V1 commonly uses flat key-value entries and a file called config; V2 uses INI-style sections and a file called config.ini. For example, these snippets illustrate different formats rather than interchangeable settings:
alpha_steps_per_mm 80
beta_steps_per_mm 80
gamma_steps_per_mm 400
[actuator]
x.steps_per_mm = 80
y.steps_per_mm = 80
z.steps_per_mm = 400Use the documentation for the installed board and firmware, back up the existing configuration, and reset the board after editing as required by that build. Smoothieware getting started, CNC mill guide and Smoothieboard V2 differences
Calculate and then calibrate motion
For a belt axis, the theoretical steps per millimeter are:
Rank #3

- 2025 New SMT802B-F Pick and Place Machine Mini Desktop 2 Head 58 Feeders LED Equipment Chip Mounter SMT for Smt Assembly Line
steps_per_mm = (motor full steps per revolution × microsteps) ÷ travel per revolutionFor a 200-step motor, 16 microsteps, a 20-tooth pulley and a 2 mm-pitch GT2 belt, travel per revolution is 20 × 2 = 40 mm, yielding (200 × 16) ÷ 40 = 80 steps/mm. That is a starting calculation, not placement accuracy. Smoothieware documents the same general relationship. Smoothieware 3D printer guide
To calibrate, command a known move, measure actual travel, and apply:
new_steps_per_mm = old_steps_per_mm × commanded_distance ÷ measured_distanceIf an 80 steps/mm axis moves 99.4 mm when commanded to move 100 mm, the adjusted value is 80 × 100 ÷ 99.4, or about 80.48 steps/mm. Resolution is the theoretical command increment; repeatability is consistency on repeated moves; accuracy is closeness to the intended point. Placement accuracy includes the mechanics, nozzle, feeder, board registration, vision and component behavior. More microsteps do not guarantee more accurate placements.
Free tools Windows power users keep installed
One-click scans. No signup required.
Current, homing and dual-Y wiring
Smoothieware configures motor current in firmware on the documented V1 system, rather than through a physical driver potentiometer. Example syntax is alpha_current 1.0; choose values for the actual motor and board, then check motor and driver heating and missed steps. Too little current can cause missed steps; too much can overheat hardware. Smoothieware 3D printer guide
Endstop inputs support homing and can be used with hard or soft limits in an appropriate configuration. Verify each switch’s state and axis assignment before homing. A wide gantry may use two Y motors to reduce racking, but whether they share a driver or use separate drivers depends on board revision, driver capacity, motor current and the desired squaring method. The project records do not provide a complete authoritative wiring diagram for every arrangement, so confirm the actual board manual and motor requirements rather than copying an assumed wiring scheme. Smoothieboard V1 specifications and CNC mill guide
Wire safely and isolate high-current loads
Do not connect a pump or solenoid directly to an unverified logic pin. Check the output voltage and current rating, use a suitable MOSFET or relay stage, and provide flyback protection for inductive loads. Use appropriate fusing, strain relief and power wiring; keep pump and motor wiring away from camera and endstop signals. Add an emergency stop that isolates hazardous motion and pneumatic hardware. Disconnect power before changing wiring, and test motion with the nozzle removed before attempting placements.
Rank #4
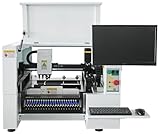
- SMT Aautomation Production Equipment Line SMT380 Manufactory Pick and Place Components Making Machine Desktop Assembly
The project coverage mentions vacuum sensors and feeder wiring but does not supply a complete authoritative schematic. Pin numbers, output polarity and allowable load must be verified against the exact Smoothieboard revision and switching hardware. A generic vacuum test command is unsafe without those details.
Build and commission in stages
Commissioning should isolate mechanical, electrical, firmware and vision problems instead of trying to tune everything at once.
- Square the frame. Assemble the base loosely, compare diagonal measurements, square the gantry, tighten progressively and check for twist or rocking. Add bed supports and adjustable camera and feeder mounts.
- Install the motion system. Fit belts, wheels, rails or actuators. Adjust wheels without binding; check full travel by hand and confirm the head cannot collide with the bed, frame or feeder bank.
- Wire and inspect. Label motors and switches, identify motor coil pairs with a meter, check supply polarity and install fuses and emergency-stop isolation. Keep the pump off the controller until its switching circuit is verified.
- Configure the controller. Identify V1 or V2, back up its configuration, set conservative current, travel, speed and acceleration, configure endstops and verify the axis map.
- Test switches and motion without a nozzle. Check endstop states, jog one motor at a time, confirm directions, home slowly, test short moves, then check full travel at low speed. Confirm emergency-stop behavior.
- Calibrate geometry. Measure commanded versus actual travel, adjust steps/mm, check backlash and gantry squareness, and test Z and rotation repeatability. Keep dated configuration notes.
- Test vacuum separately. Check pump, valve, tubing, nozzle vacuum and release behavior using representative parts. Add a vent or blow-off path if needed; assess whether pump vibration or electrical noise affects cameras and motion.
- Prove one feeder. Calibrate its pickup point, height, tape pitch and peel behavior; repeat feed-and-pick cycles before adding more feeders.
- Configure cameras and OpenPnP. Establish controller communications, axis directions and units; configure nozzle, vacuum, feeder and camera devices; calibrate camera-to-nozzle and nozzle-tip offsets; set board fiducials and perform a dry run.
- Place simple parts first. Use an inexpensive test board and common passives, inspect results, and log pickup failures and offsets before trying polarized or fine-pitch components.
Common G-code such as G28 for homing, G0 X50 Y50 F1000 for a move, and G0 A90 F500 for a rotary-axis move is only safe when the axis map, limits, coordinate system and feed-rate interpretation are known. Smoothieware configurations and host software can differ; first test short moves in a safe area. Smoothieware documentation commonly uses M119 for endstop status in relevant configurations, but verify the command and response for the installed firmware. Smoothieware delta documentation
Feeders: start simple, then automate
The original machine used 3D-printed 0816 automatic feeders and drag feeders. A sensible progression is hand-loaded trays or component piles, cut-tape holders, passive strip feeders, drag or push-pull feeders, and only then motorized tape feeders or full reels. Automatic feeders can raise throughput, but often become the most failure-prone subsystem because they must present each pocket at a stable position and height.
For each feeder, record its ID, package, tape pitch, pocket center, pickup height, peel position, feed increment, polarity, compatible nozzle and whether vision correction is needed. Use guides or fences to stop cut tape wandering. If the nozzle repeatedly misses, check feeder coordinates and tape pitch; variable pickup height points to tape support or feeder flex; parts stuck to cover tape point to peel geometry; erratic rotation may mean parts shift in pockets or vacuum centering is poor.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Configure OpenPnP and coordinate systems
OpenPnP must be taught how the machine’s axes, camera offsets, nozzles, feeders and board coordinates relate. Do not assume it automatically resolves axis direction, origin, rotation sign or units. A sound setup proceeds from reliable motion to vision and then placements:
Best Value

- ✔️【High Precision Placement】Features advanced vision alignment and high-accuracy stepper servo motors for precise SMD component placement — ideal for fine-pitch ICs and small resistors/capacitors.
- ✔️【High speed and stability】Double-head mounting design + stepper servo motor drive, the mounting speed reaches 3000CPH, supporting 8 hours of continuous stable operation.
- ✔️【Compact and Space-Saving Design】Desktop-grade area (53" x 31"), low-cost startup of professional SMT production line, home power supply (110V) driven, power consumption is only 230W
- ✔️【User-Friendly Interface】The fully graphical English operation interface allows novices to quickly get started without any programming experience. Just import the X, Y coordinate file and it will be ready for use.
- ✔️【Independent R&D Pneumatic Feeding System】The film collecting mechanism is similar to the Well-known Brand feeder, which is not easy to jam and convenient to replace the reels.
- Install OpenPnP and select or create a machine configuration for the controller.
- Establish communications and confirm axis directions, units, home positions and safe travel.
- Define nozzle and vacuum actuators; configure feeders and camera devices.
- Focus cameras at their working distances and use stable diffuse lighting.
- Calibrate nozzle tip and camera-to-nozzle offsets.
- Define board fiducials and confirm that their detected positions map to the board correctly.
- Import or create board placement data, associate components with feeders, and run a dry path.
- Place low-cost passives on a test board, inspect them and correct offsets before moving to more demanding packages.
PCB data has distinct roles: the bill of materials identifies components, centroid or position data gives locations and angles, footprints describe pads and package geometry, and fiducials provide physical references for aligning design coordinates to the board. Common import problems include mirrored rotations, wrong origins, bottom-side data treated as top-side, missing fiducials, or package names that do not match feeder assignments.
Diagnose common failures
| Symptom | Likely cause | Recovery |
|---|---|---|
| Axis homes in the wrong direction | Homing direction, endstop assignment, logic inversion or origin mismatch | Remove the nozzle, inspect switch state, change one setting at a time, test slowly and re-home. |
| Motor vibrates but does not turn | Incorrect coil pairing, loose connector, low current or mechanical binding | Identify coil pairs with a meter, inspect connectors, test the uncoupled motor and set current within limits. |
| Placements are consistently offset | Board origin, nozzle offset, camera calibration, fiducial transform or fixture movement | Check a calibration grid, isolate one axis at a time, recalibrate offsets and secure the board. |
| Placement error varies from part to part | Loose tape, weak or inconsistent vacuum, part movement, nozzle wobble, missed steps or electrical noise | Reduce acceleration, inspect pickup, secure tape, check nozzle and vacuum, and separate pump wiring from signals. |
| Part is picked up but will not release | Residual vacuum, slow valve, no vent path or contaminated nozzle | Add or tune a vent/blow-off, increase release dwell, and inspect the nozzle and valve response. |
| Camera detection is inconsistent | Reflections, unstable lighting, poor focus, vibration or unsuitable exposure | Use diffuse lighting and a matte background, stabilize focus and exposure, and isolate the camera from vibration. |
Performance, cost and controller choice
The builder’s reported rate of about 1,200 parts per hour followed a change from Ethernet communication to USB serial on that machine. The sources do not establish that USB is universally faster, nor do they provide an independently measured rate, placement yield or a repeatable test method. A nominal parts-per-hour figure says little about usefulness if pickup failures, feeder reloads, vision rejects, setup time or rework dominate. Track pickup success, first-pass placements, reject rate, setup and reload time, repeatability and package range alongside cycle rate. Project logs
No verified current bill of materials or total build cost is established here. The OpenBuilds/Smoothieboard arrangement may suit a maker who enjoys mechanical and firmware integration, has a limited or specialized assembly need, and is willing to iterate. It is a poor fit when the requirement is validated placement accuracy, production uptime, formal support or fast setup without calibration work. For very small runs, compare the full workflow cost—including feeder preparation, maintenance and rework—with manual placement or contract assembly rather than comparing only machine hardware costs.
Smoothieboard makes sense when reproducing the documented architecture or when compatible hardware is already available. A new buyer should first verify board availability, exact firmware/configuration syntax, driver capacity and compatibility with the chosen OpenPnP setup. Smoothieboard is not established as the best current controller choice; OpenPnP supports a wider ecosystem of DIY machines and motion-control options. OpenPnP hardware ecosystem
Who should build it?
This design is best approached as a systems-integration project by a maker comfortable with motion mechanics, wiring, firmware and calibration. A sensible first success is not a dual-head machine at a headline cycle rate: it is a square, repeatable single-head machine that homes reliably, picks from one feeder, recognizes a fiducial and places simple components in the right orientation. Expand feeder count, nozzle options and speed only after that workflow is dependable.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.
Leave a Reply