Do these 3 things before closing this tab:
1Scan for outdated or missing drivers - takes under a minute2Clear out junk files and repair common Windows errors3Fix the driver behind crashes, sound loss and screen glitchesSome links on this page are affiliate links: if you buy through them we may earn a commission, at no extra cost to you.
Yes, you can build a DIY Roomba Virtual Wall. The practical version uses a Nano-class microcontroller, a 940-nm infrared LED, a current-limiting resistor, and usually an NPN transistor to drive the LED. The difficult part is not producing infrared light; it is generating a modulated signal with timing your particular Roomba recognizes, then aiming that signal at the robot’s sensors.
This is a good maker project for blocking a doorway, pet area, cables, or clutter. It is not a life-safety barrier, and it should not be trusted without repeated model-specific testing.
What a Roomba Virtual Wall actually does
A Virtual Wall is not a physical wall and does not use Wi-Fi or radio. It emits a coded infrared signal across the floor. When a compatible Roomba detects that signal with its front-facing sensors, it behaves as though it has reached a boundary and turns away.
Recommended Free Tools
Some iRobot accessories support two different behaviors:
#1 Best Overall

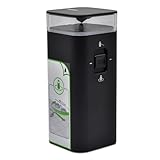
- Dual-Mode Virtual Wall Barrier: Features Halo Mode (creates a 3ft/0.9m circular barrier) and Beam Mode (projects a 10ft/3m infrared beam) to precisely contain or exclude your robot vacuum from protected areas
- Battery-Powered with Low-Energy Indicator: Operates on 2 AA batteries (not included). Clear visual alert activates when battery replacement is required-indicator light remains off during normal operation
- iRobot Roomba Compatibility: Fits Roomba 800/900 Series, e/i/s Series (e5/e6/i4/i4+/i6/i6+/i7/i7+/i8/i8+), 7150/5150/7550, e5120/e5152/e5158, i7158/i7550, Combo Essential Y0140 & jet m6. Excludes: 500/700 Series & pre-2015 600 Series models
- Effortless Setup and Reliable Operation: Activate barrier in seconds: Switch mode, 5 confirmation flashes, barrier engages. No app or syncing needed
- Protect Delicate Zones and Boost Cleaning Efficiency: Block access to pet bowls, cables, or fragile items. Maintains Roomba's cleaning path integrity with infrared precision
- Virtual Wall or fence mode: projects a boundary line across a doorway or open area.
- Halo or force-field mode: creates a localized exclusion zone around an object such as a pet bowl.
A single forward-facing DIY LED can reproduce the first behavior in some models, but it should not automatically be treated as an equivalent replacement for every OEM accessory mode. Factory hardware may use additional optical geometry, including signals directed upward or around the enclosure.
The hobbyist designs documented by misc.ws, Hackster, and public Arduino examples use a modulated infrared signal rather than a continuously illuminated LED.
Why the LED must be modulated
A continuously powered IR LED is generally insufficient. Sunlight, lamps, and reflections also contain infrared energy, so the Roomba needs a recognizable carrier and pulse pattern to distinguish a beacon from ambient light.
The commonly reproduced design uses:
- Approximately 38 kHz carrier frequency
- Short bursts of that carrier
- Timed spaces between the bursts
- Repeated transmission rather than one isolated pulse
One published Arduino implementation starts with roughly equal 1-ms mark and 1-ms space intervals. That is a useful starting point, not a universal official specification. Another builder measured an OEM unit with a substantially different envelope—approximately 500 microseconds on, 7.5 milliseconds off, repeated three times, followed by a pause of roughly 132 milliseconds. A discussion of that work also reports that a Roomba 880 did not respond to the simpler 1-ms pattern.
In other words, “38 kHz” describes the carrier used by many hobbyist implementations; it does not prove that one timing pattern works with every Roomba generation.
Rank #2

- 2 pack of Dual Mode Virtual Wall Barriers gives you greater control over where your robot cleans
- Virtual Wall mode keeps your robot in the rooms you want cleaned and out of the ones you don't
- Halo mode keeps your robot away from items you want to protect, like your pet's food and water bowls
Choose the build before buying parts
| Build | Best for | Main trade-off |
|---|---|---|
| Arduino Nano | Beginners, prototyping, USB power, easy debugging | Larger and less power-efficient than a purpose-built low-power circuit |
| ATtiny85 | Compact, battery-powered permanent installation | More difficult programming and debugging |
| PIC12F683 or similar PIC | Small, inexpensive final circuits | Older toolchains and less approachable development |
| OEM Virtual Wall | Compatibility and convenience | Costs more and may be difficult to find for discontinued models |
Use a Nano for the first working prototype. Once the signal is proven, move to an ATtiny or PIC if the enclosure must be small or battery life matters. If the robot protects stairs, valuable objects, or an area where failure would be costly, an official or confirmed-compatible replacement is the more sensible choice.
Parts for a Nano prototype
Essential parts
- Arduino Nano or compatible Nano-class board
- 940-nm infrared LED, preferably with a reasonably narrow beam
- Current-limiting resistor for the IR LED
- Breadboard and jumper wires
- USB cable
- USB power supply or battery pack
Useful upgrades
- 2N2222A, 2N3904, or similar NPN transistor
- Base resistor for the transistor
- Power switch
- Status LED and resistor
- Battery holder or protected rechargeable battery assembly
- Project box, tube, or 3D-printed directional LED holder
The resistor is not optional. Never connect the IR LED directly to a GPIO pin without suitable current limiting. The resistor value depends on the LED’s forward voltage, the supply voltage, the desired pulse current, and the ratings of the LED and driver. Calculate it from the component datasheets rather than copying a value blindly from a different circuit.
Basic transistor-driven circuit
The microcontroller pin should control the transistor; the transistor should switch the pulsed LED current:
Arduino output pin
        |
   base resistor
        |
     NPN transistor
        |
   IR LED + resistor
        |
       GND
Connect the Nano, transistor, LED, and power supply to a common ground. Check the pinout of the exact transistor you bought—2N2222A and 2N3904 packages do not all share the same physical pin arrangement.
The transistor is useful because a GPIO pin may not be able to provide the desired pulsed LED current safely. It can also improve range. The LED current must still remain within the LED, transistor, board, and power-supply limits. Higher current is not automatically better: it can overheat components, drain batteries, and overwhelm the receiver at close range.
Rank #3
- Virtual wall barrier compatible with iRobot Roomba e/i/s/j series, including e5, e6, i4, i4+, i6, i6+, i7, i7+, i8, i8+, S9, S9+, for Roomba e5, for Roomba e5150, for Roomba e5120, for Roomba e5152, for Roomba e5154, for Roomba e5158, for Roomba e515840, for Roomba e6, for Roomba e6198, for Roomba e619820, for Roomba i7, for Roomba i7+, for Roomba i7158, for Roomba i7550, for Roomba i755020, for Roomba i7558, and Braava Jet M6 vacuum cleaners
- Not compatible with Roomba 500 and 700 series. Some 600 series produced before May 2015 may not be supported
- Dual Modes: Instructions For Use: After switching up the mode(Halo/Beam), the light flashes 5 times and then goes out. The virtual wall barrier is formed. which allows a 4-foot barrier around the device, to keep Roomba out of this area. Beam Mode, which creates a 10ft beam of infrared, to help keep Roomba in or out of a specific area
- Customer Service: Rest assured with 30 days Refund and 12 months Warranty; you can click on seller store on right corner “ask a question” and contact seller directly
Firmware: separate the carrier from the protocol
Think of the firmware as two layers:
- Carrier generation: produce approximately 38-kHz pulses.
- Protocol envelope: turn that carrier on and off according to a repeated mark-and-space pattern.
Older public examples use Arduino IR libraries and assign the transmitter to a board-specific pin, including pin 3 in one example. However, Arduino IR libraries have changed APIs and timer behavior over time. A sketch written for an older IRremote release may not compile unchanged with a current release.
Windows Errors? Fix Them Before They Spread
Repair common Windows errors and clear accumulated junk for a smoother, more stable PC - no reinstall needed.Free scan · no reinstallOutdated Drivers Are Slowing You Down
One free scan finds every outdated or missing driver and matches the right update for your exact hardware.Free scan · exact hardware matchFor that reason, do not describe an unversioned sketch as guaranteed plug-and-play. Either pin the exact library version used by your project or implement the carrier with the board’s timer hardware. The following is deliberately pseudocode showing the structure rather than pretending to be a universal upload-and-run program:
configure output pin
configure timer for approximately 38 kHz

loop forever:
    enable carrier
    wait for mark duration
    disable carrier
    wait for space duration
    repeat the burst pattern
    wait briefly
Start with the published 1-ms mark and 1-ms space pattern if your target is an older, compatible Roomba. If the robot ignores it, test the alternative OEM-like envelope instead of immediately increasing LED power. Change one variable at a time and record the result.
The public references at this Arduino example and this reverse-engineered command reference are useful starting points, but they are hobbyist documentation rather than a current iRobot compatibility guarantee.
Positioning matters as much as the code
The beam must intersect the Roomba’s front sensor height. Mounting the LED too high can allow the robot to pass underneath the effective signal; mounting it too low or pointing it into furniture can make the boundary unreliable.
Rank #4

- Dual Mode Virtual Wall Barrier-This Virtual wall barrier fit for irobot Roomba 800 Series, Roomba 900 Series, Roomba i e & s Series Vacuum Cleaner, Only Compatible with iRobot Roomba e/i/s Series e5 e6 i4 i4+ i6 i6+ i7 i7+ i8 i8+ Robots7150,Roomba 5150,Roomba 7550,Roomba e5,Roomba e5150,Roomba e5120,Roomba e5152,Roomba e5154,Roomba e5158,Roomba e515840,Roomba e6,Roomba e6198,Roomba e619820,Roomba i7,Roomba i7 +,Roomba i7158,Roomba i7550,Roomba i755020,Roomba i7558 ,jet m6,Roomba Combo Essential Robot Y0140. NOT for roomba 500 700 series, Partial 600 series produced before 2015 may not be used.
- Power the Virtual wall Barrier-Power Support-2 x AA battery (Not included in the package). Low Battery Indicator:The indicator light will remain off during normal use, and will light up when the battery is low and needs to be replaced. Instructions For Use:After switching up the mode(Halo/Beam), the light flashes 5 times and then goes out. The virtual wall barrier is formed.
- Dual Modes wall Barrier-Halo Mode, which allows a 3' barrier around the device, to keep Roomba out of this area. Beam Mode, which creates a 10ft beam of infrared, to help keep Roomba in or out of a specific area.
- Roomba Wall Barrier-Keep the roomba away from the areas you don’t want, make it working more efficiently with the virtual wall barrier. Move the switch to the virtual wall position, the device will create a linear barrier to block an area with a maximum width of 3 meters (10 feet). Move the switch to the Halo position to create a circular barrier. This will prevent the robot from approaching the area you want to protect, and the Halo barrier can radiate within a radius of about 60 cm (24 inches) with the device as the center.
- Easy set Virtual Wall Barrier-Set-up easily and quickly. Low battery indicator.Contact us any time if you have any questions we will respond in 24 hours.
Position the beacon:
- Low enough for the front sensors to see the beam
- Pointed across the doorway or restricted boundary
- Far enough from the travel path that the robot cannot strike it
- Inside a stable enclosure that cannot be nudged out of alignment
- With a narrow beam or tube if you need a defined boundary rather than room-wide illumination
A bare LED may stop the Roomba from crossing the intended line while still allowing it to collide with the beacon from the side. The ATtiny85 design documented by Hackster notes that a compact DIY unit lacks some of the OEM device’s optical protection geometry. Treat the enclosure and beam direction as part of the design, not as cosmetic finishing work.
First-test procedure
- Place the beacon several feet from the intended doorway or boundary.
- Start the Roomba on the permitted side.
- Confirm that it approaches and turns away repeatedly.
- Move the beacon laterally and vertically to find the most reliable sensor height.
- Test several approach angles, not just a straight-on approach.
- Repeat the test with the room’s normal lighting and, if relevant, bright sunlight.
- Secure the enclosure only after the boundary works consistently.
Use a phone camera only as a rough check that the LED emits some infrared light. A visible glow on a camera does not prove that the carrier frequency, timing, intensity, direction, or protocol is correct.
Range expectations
Do not assume OEM-equivalent range. A builder reported approximately 10 feet of reliable range for a particular PIC-based design, but that is one project’s result, not a general specification.
Practical range depends on:
- LED output power and beam angle
- Transistor drive and resistor selection
- Carrier accuracy and protocol timing
- Optical tube or enclosure design
- Roomba sensor height and approach angle
- Battery voltage as it falls
- Sunlight and other infrared sources
If the unit works only at close range, first improve alignment and directionality and verify the power source. A transistor driver may help, but do not exceed component ratings simply to chase a longer distance.
Power choices
USB-powered Nano
USB power is convenient for testing, a permanent installation near an outlet, or a home-automation project. It avoids battery maintenance, but the cable can become a trip or vacuum hazard and is less discreet.
Best Value

- Virtual wall barrier compatible with iRobot Roomba e/i/s/j series, including e5, e6, i4, i4+, i6, i6+, i7, i7+, i8, i8+, S9, S9+, for Roomba e5, for Roomba e5150, for Roomba e5120, for Roomba e5152, for Roomba e5154, for Roomba e5158, for Roomba e515840, for Roomba e6, for Roomba e6198, for Roomba e619820, for Roomba i7, for Roomba i7+, for Roomba i7158, for Roomba i7550, for Roomba i755020, for Roomba i7558, and Braava Jet M6 vacuum cleaners
- Not compatible with Roomba 500 and 700 series. Some 600 series produced before May 2015 may not be supported
- Dual Modes: Instructions For Use: After switching up the mode(Halo/Beam), the light flashes 5 times and then goes out. The virtual wall barrier is formed. which allows a 4-foot barrier around the device, to keep Roomba out of this area. Beam Mode, which creates a 10ft beam of infrared, to help keep Roomba in or out of a specific area
- Customer Service: Rest assured with 30 days Refund and 12 months Warranty; you can click on seller store on right corner “ask a question” and contact seller directly
Three AA batteries with an ATtiny
An ATtiny85 design documented by Hackster uses three AA batteries and low-power sleep behavior, reporting operation for many months. This architecture is better suited to an always-on compact beacon than a full Nano, provided the builder is comfortable programming and debugging the smaller controller.
Rechargeable lithium battery
An advanced project uses a 3.7-V, 850-mAh LiPo with a TP4056 charging and protection board and reports average current around 6 mA for that particular design. A lithium assembly needs an enclosure that prevents puncture, compression, exposed contacts, and accidental short circuits. Use a proper protected charging arrangement and keep the battery where the Roomba cannot strike, drag, or crush it.
Compatibility: the qualification most DIY guides omit
The available evidence is concentrated on older Roomba families, especially models associated with 500- and 600-era Virtual Wall behavior. A reverse-engineered reference identifies a “Roomba 500 Virtual Wall” command value of 162 and separate lighthouse or beam fields, but this is hobbyist documentation—not a current iRobot guarantee.
Quick wins for a faster PC:
Clear out junk files and repair common Windows errorsFree Scan →Scan for outdated or missing drivers - takes under a minuteDriver Scan →Before building around the project, identify the exact model number and determine whether that robot originally supported physical Virtual Wall accessories. A DIY infrared beacon should not be assumed to reproduce app-based Keep Out Zones on newer smart-mapping models. App features and physical infrared accessories are different systems.
Test the beacon on the actual robot before relying on it around stairs, pets, fragile objects, cords, or restricted rooms. Low batteries, a shifted enclosure, direct sunlight, blocked sensors, timing differences, or a software and hardware mismatch can all cause failure.
Troubleshooting by symptom
| Symptom | Likely checks |
|---|---|
| Roomba ignores the beacon | Check LED polarity, resistor, wavelength, output pin, library mapping, transistor wiring, battery voltage, 38-kHz generation, beam height, direction, timing, and model compatibility. |
| Works only at close range | Check LED current, beam width, transistor drive, battery strength, resistor value, and alignment with the robot’s sensors. |
| Works intermittently | Repeat the burst pattern, compare the 1-ms pattern with the alternative OEM-like timing, reduce distance, block sunlight, and prevent the enclosure from moving. |
| Battery drains quickly | Use sleep modes, reduce unnecessary status LEDs, check for a continuously driven LED, and consider an ATtiny-based design. |
| Robot collides with the box | Use a stable base, narrow the forward beam, move the enclosure outside the travel path, and add a physical guard. |
If possible, test with a known-good OEM Virtual Wall. That separates a problem with the robot or its sensors from a problem in the DIY circuit.
DIY versus buying
| Criterion | DIY Nano or ATtiny | OEM barrier |
|---|---|---|
| Initial cost | Low when tools and parts are already available | Higher purchase cost |
| Compatibility | Must be verified on the exact robot | Better when officially matched |
| Build effort | Requires wiring, programming, optics, and testing | Minimal setup |
| Battery life | Highly dependent on design | Designed for its product ecosystem |
| Flexibility | Can add timers, buttons, automation, and custom modes | Limited to supported functions |
| Failure visibility | May be difficult to notice | Usually has product indicators or known behavior |
DIY makes sense when experimentation, customization, or several inexpensive barriers matters more than convenience. Buy an official or confirmed-compatible replacement when reliability matters more than the project itself. Parts may cost only a few dollars in an older build, but tools, an enclosure, failed components, and your time can make the finished project more expensive than expected.
What’s actually slowing this PC down?
Pick the symptom - the matching free tool is one click away.
Advanced improvements
- Add sleep mode and wake the transmitter periodically to extend battery life.
- Add battery-voltage monitoring so a weak battery does not silently reduce range.
- Use a switch and status indicator for easier servicing.
- Provide selectable timing patterns for different tested Roomba families.
- Use a 3D-printed holder or optical tube after the electronics work.
- Install the unit permanently and control it with home automation, while retaining a manual override.
Safety checklist
- Do not treat the beacon as a physical or life-safety barrier.
- Do not rely on it to prevent a robot from reaching stairs without an independent safeguard.
- Limit LED current and verify transistor, wiring, and battery ratings.
- Protect rechargeable lithium cells from puncture, crushing, and short circuits.
- Keep USB cables and enclosures out of the robot’s path.
- Test after every battery change, relocation, firmware change, or enclosure modification.
The core electronics are straightforward; reliable behavior is not universal. Build the Nano prototype, verify the timing and beam on the exact Roomba model, and only then optimize the enclosure or battery system.
Quick Recap
Product prices and availability are accurate as of the date/time indicated and are subject to change. Any price and availability information displayed on Amazon at the time of purchase will apply.
Leave a Reply